Introduction
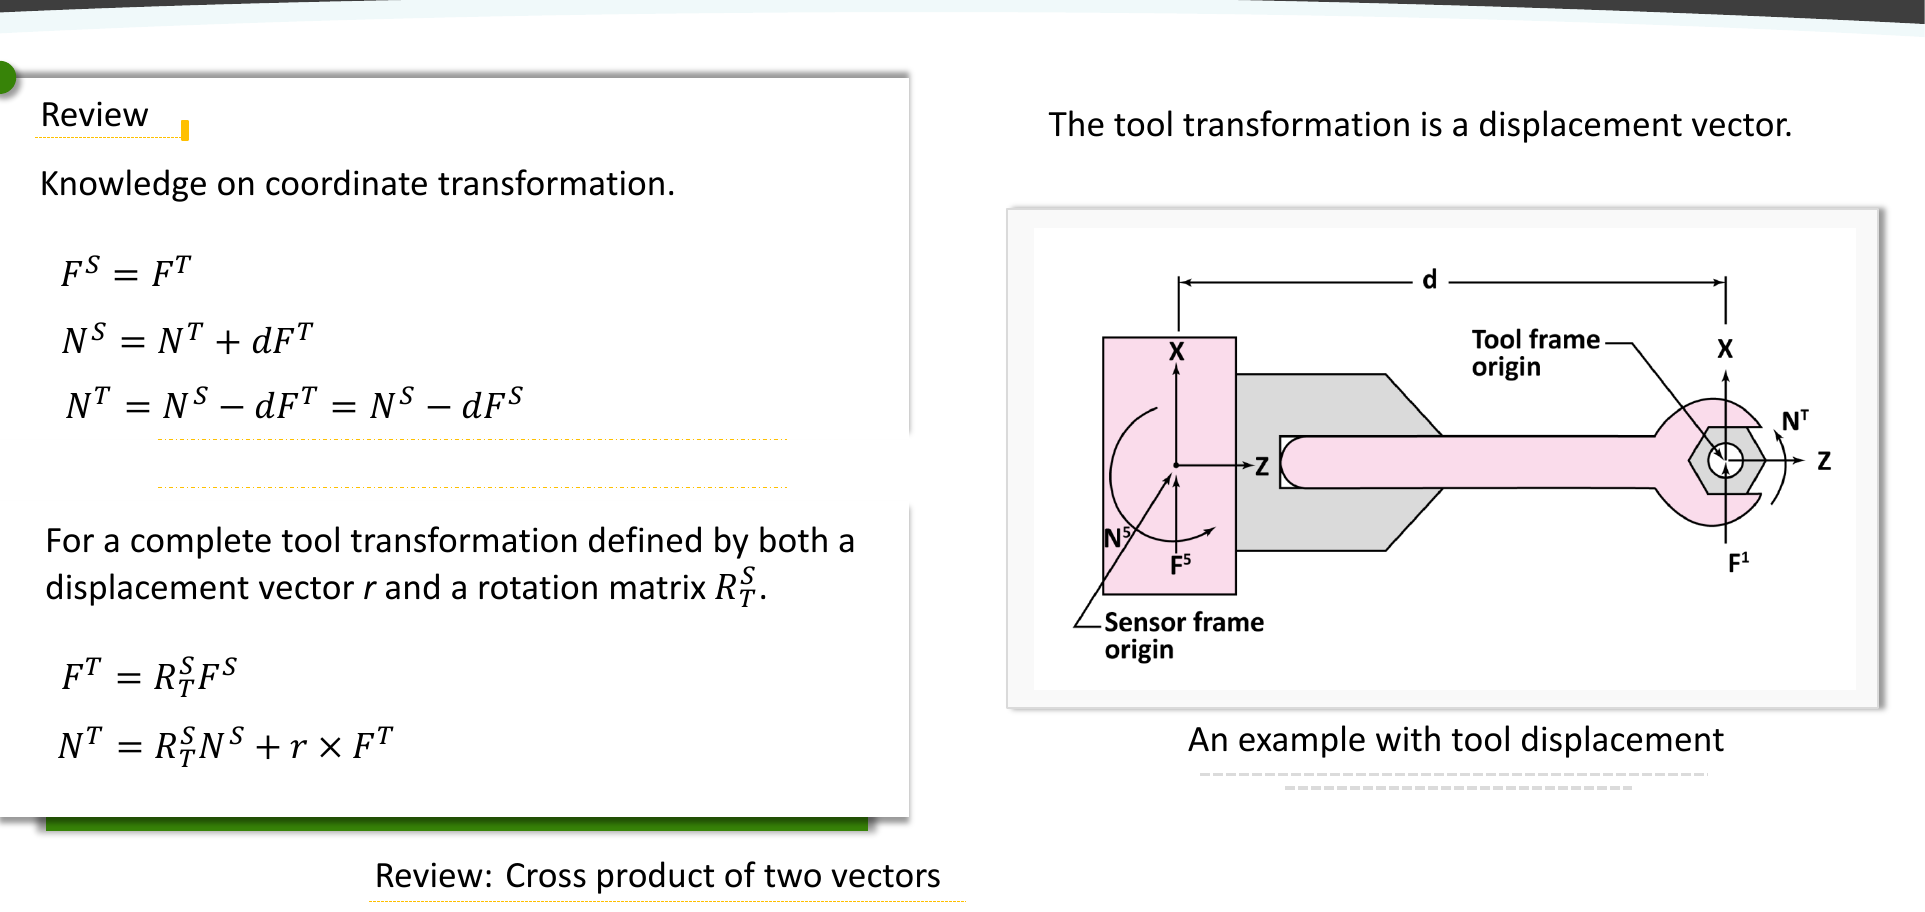
A wrist force sensor is calibrated in a frame at the centre of the sensor, called the sensor frame . But you usually need the force and torque at the tool tip, in the tool frame . The tool transformation changes the values from to .
How it works
Displacement only
If the tool frame is only displaced by a vector from the sensor frame, the force is the same, but the moment changes:
Displacement and rotation
For a full tool transformation with a displacement vector and a rotation matrix :
Key equations
In matrix form:
Use a force vector . Then:
where is the force moment transformation from the sensor frame to the tool frame.