Introduction
A feedback control system uses data from sensors to keep the manipulator on its path. It is the basic structure of Robot Control.
How it works
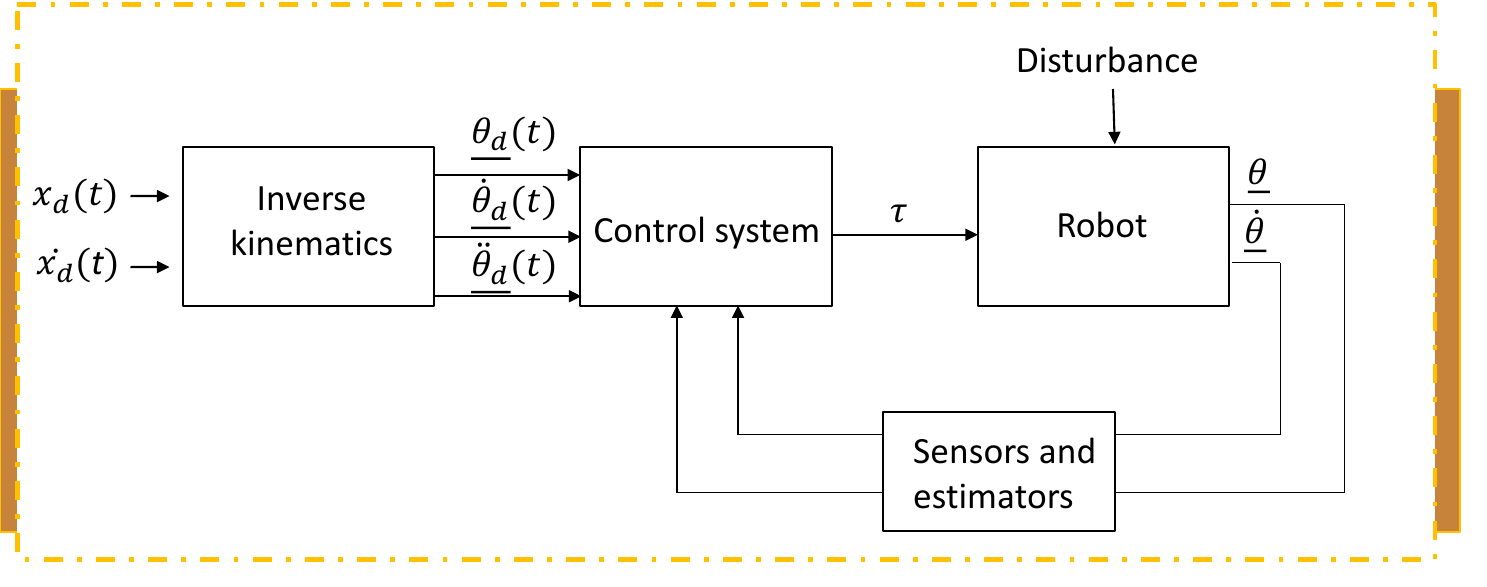
flowchart LR
    X["x_d(t), x_d-dot(t)"] --> IK["Inverse kinematics"]
    IK -->|"θ_d, θ_d-dot, θ_d-ddot"| C["Control system"]
    C -->|"τ"| R["Robot"]
    D["Disturbance"] --> R
    R -->|"θ, θ-dot"| S["Sensors and estimators"]
    S --> C
- The desired tool path and velocity go into inverse kinematics
- Inverse kinematics gives the desired joint position , velocity and acceleration
- The control algorithm compares these with the measured values and sends torques to the joints
- Sensors and estimators measure the actual joint position and velocity and feed them back
Disturbances
Disturbances are inputs that you cannot control, but they also change the behaviour of the system. So the controller must also reject the disturbances, which means it must reduce their effects.