Introduction
A control system must keep good performance (small errors) even when there is an external disturbance. This note shows how the partitioned controller handles a disturbance, and how an integral term removes the steady state error.
Effect of a disturbance
Add a disturbance force to the mass spring system:
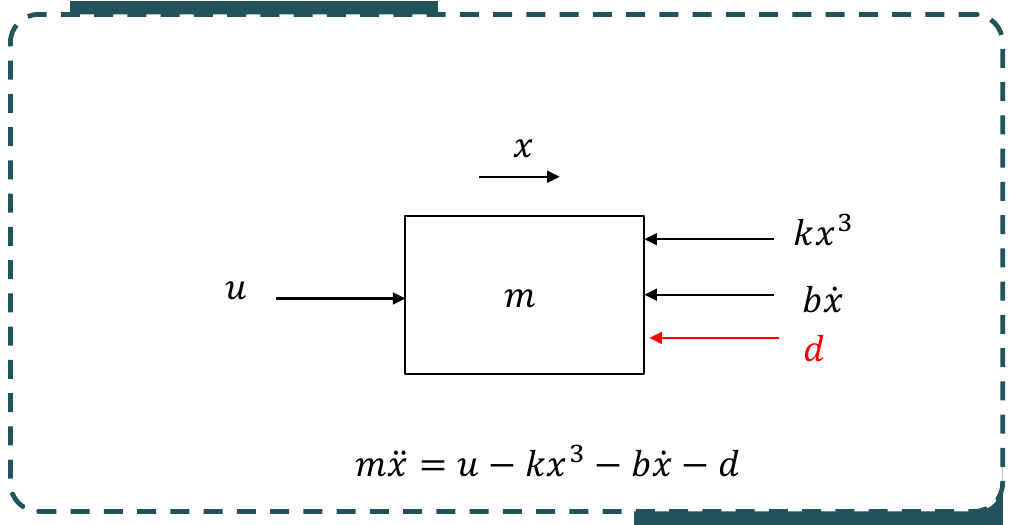
Use the same controller:
| Symbol | Meaning |
|---|---|
| , , | mass, friction coefficient and spring constant of the mass spring system |
| position of the mass | |
| desired position | |
| position error, | |
| force applied to the mass | |
| position (proportional) gain | |
| velocity (derivative) gain |
The non-linear terms cancel, and the error equation becomes:
Laplace transform:
| Symbol | Meaning |
|---|---|
| Laplace transform of the error | |
| Laplace transform of the disturbance |
Steady state error
For a constant disturbance , use the final value theorem:
A higher position gain gives a smaller steady state error, but the error does not go to zero.
Adding an integral term
To remove the steady state error, add an integral term to the servo law:
| Symbol | Meaning |
|---|---|
| input from the servo portion | |
| integral gain |
The error equation becomes:
For a constant disturbance:
The integral term removes the steady state error. But the system is now third order. See Third Order System for how to choose the gains.