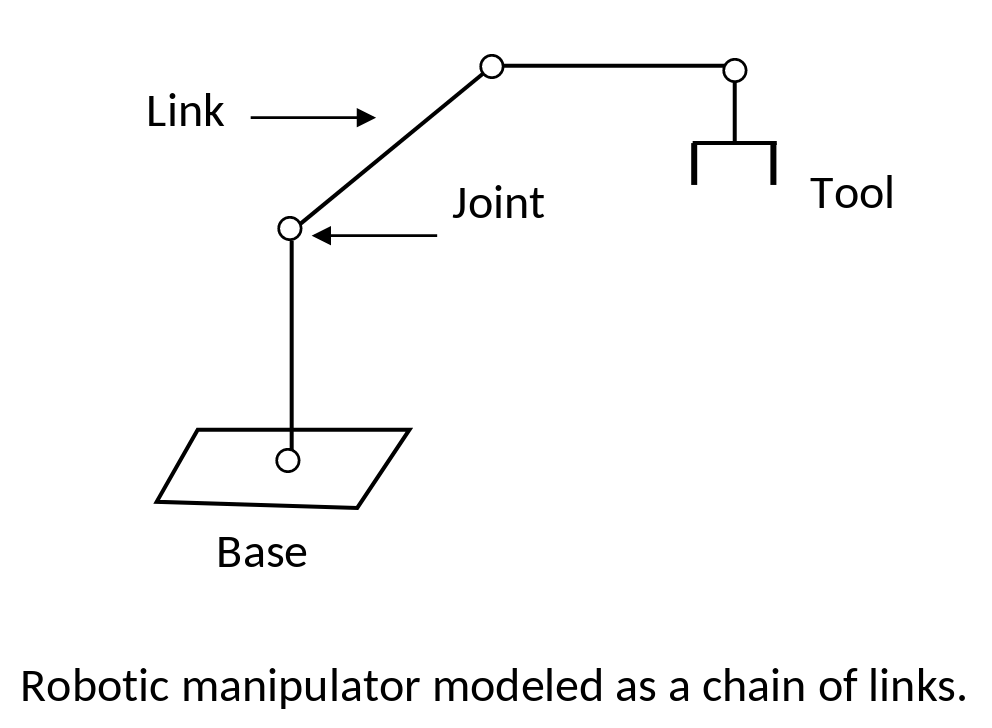
- A robot has many parts that are connected via joints
- a middle part of robot arm will have 2 joints connected to it, 1 at the top and 1 at the bottom
- every part of the robot arm is called a Link
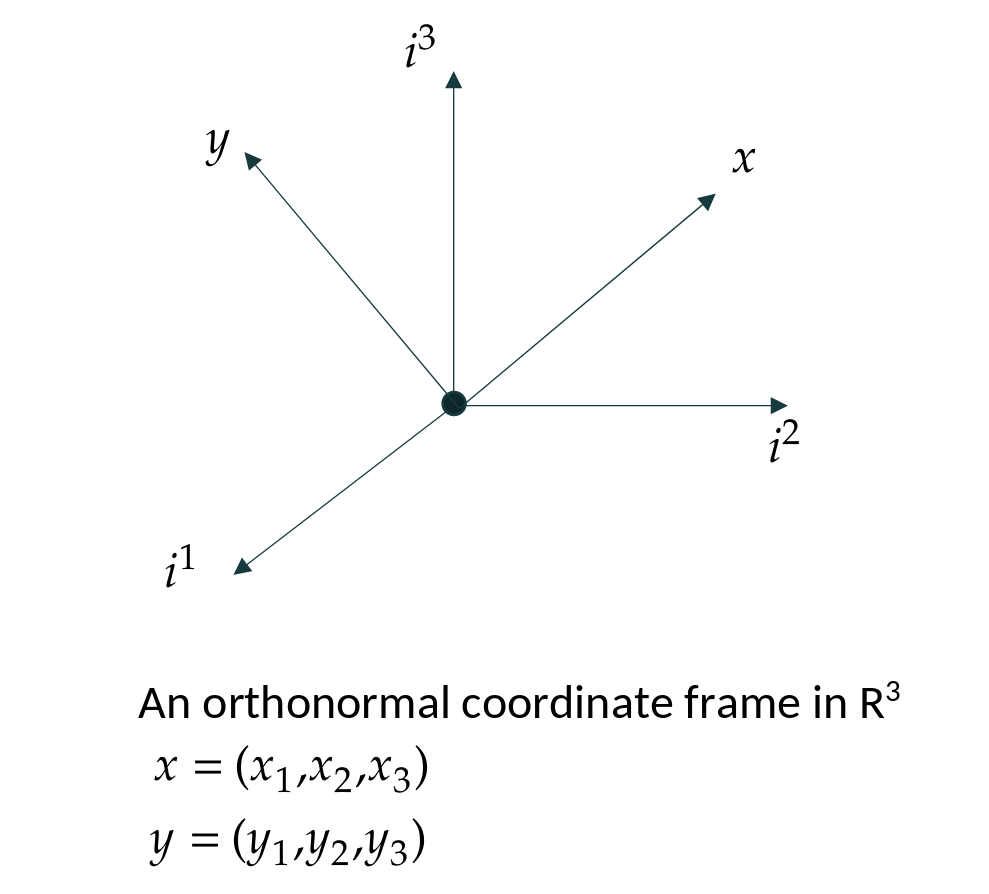
- we also have a Coordinate Frame that is fixed the link
- this frame is connected to the top of the link (assuming the base link is at the bottom and the arm is pointing up)
- so when the bottom joint rotates, our frame (which is at the top and fixed to that particular link) moves, it is transformed with respect to our base frame