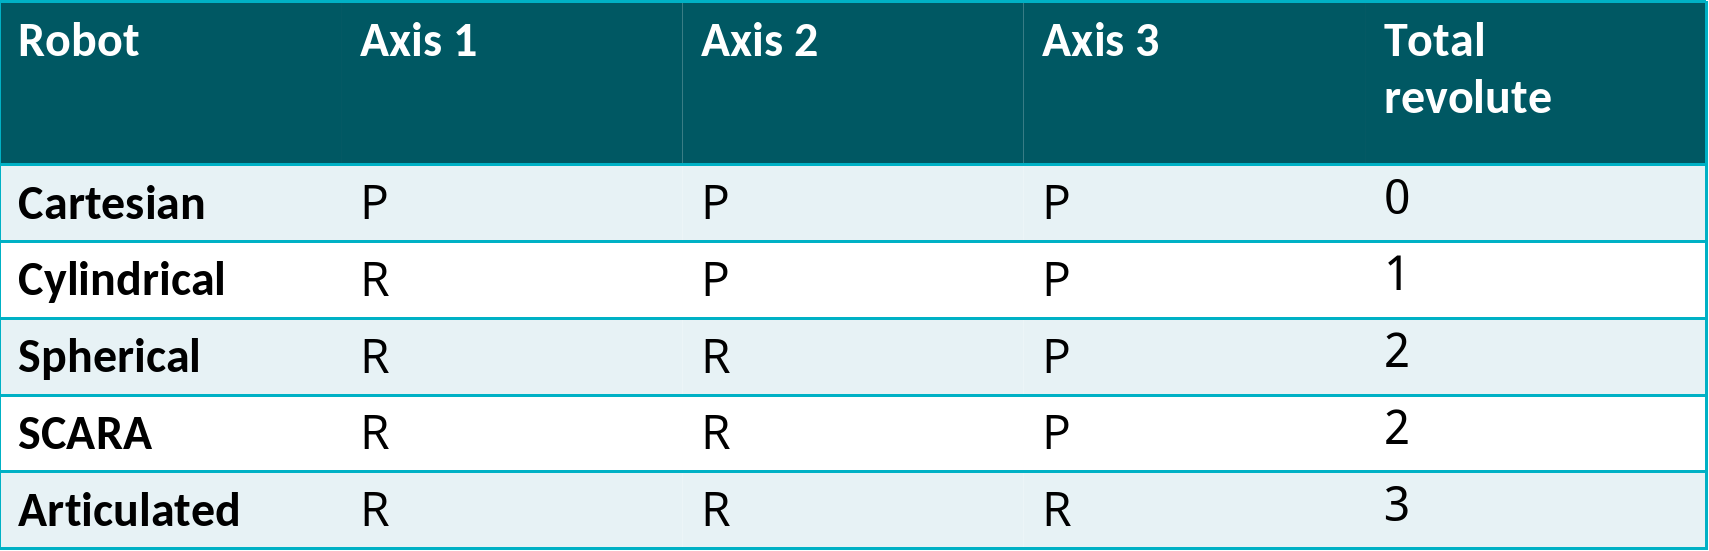
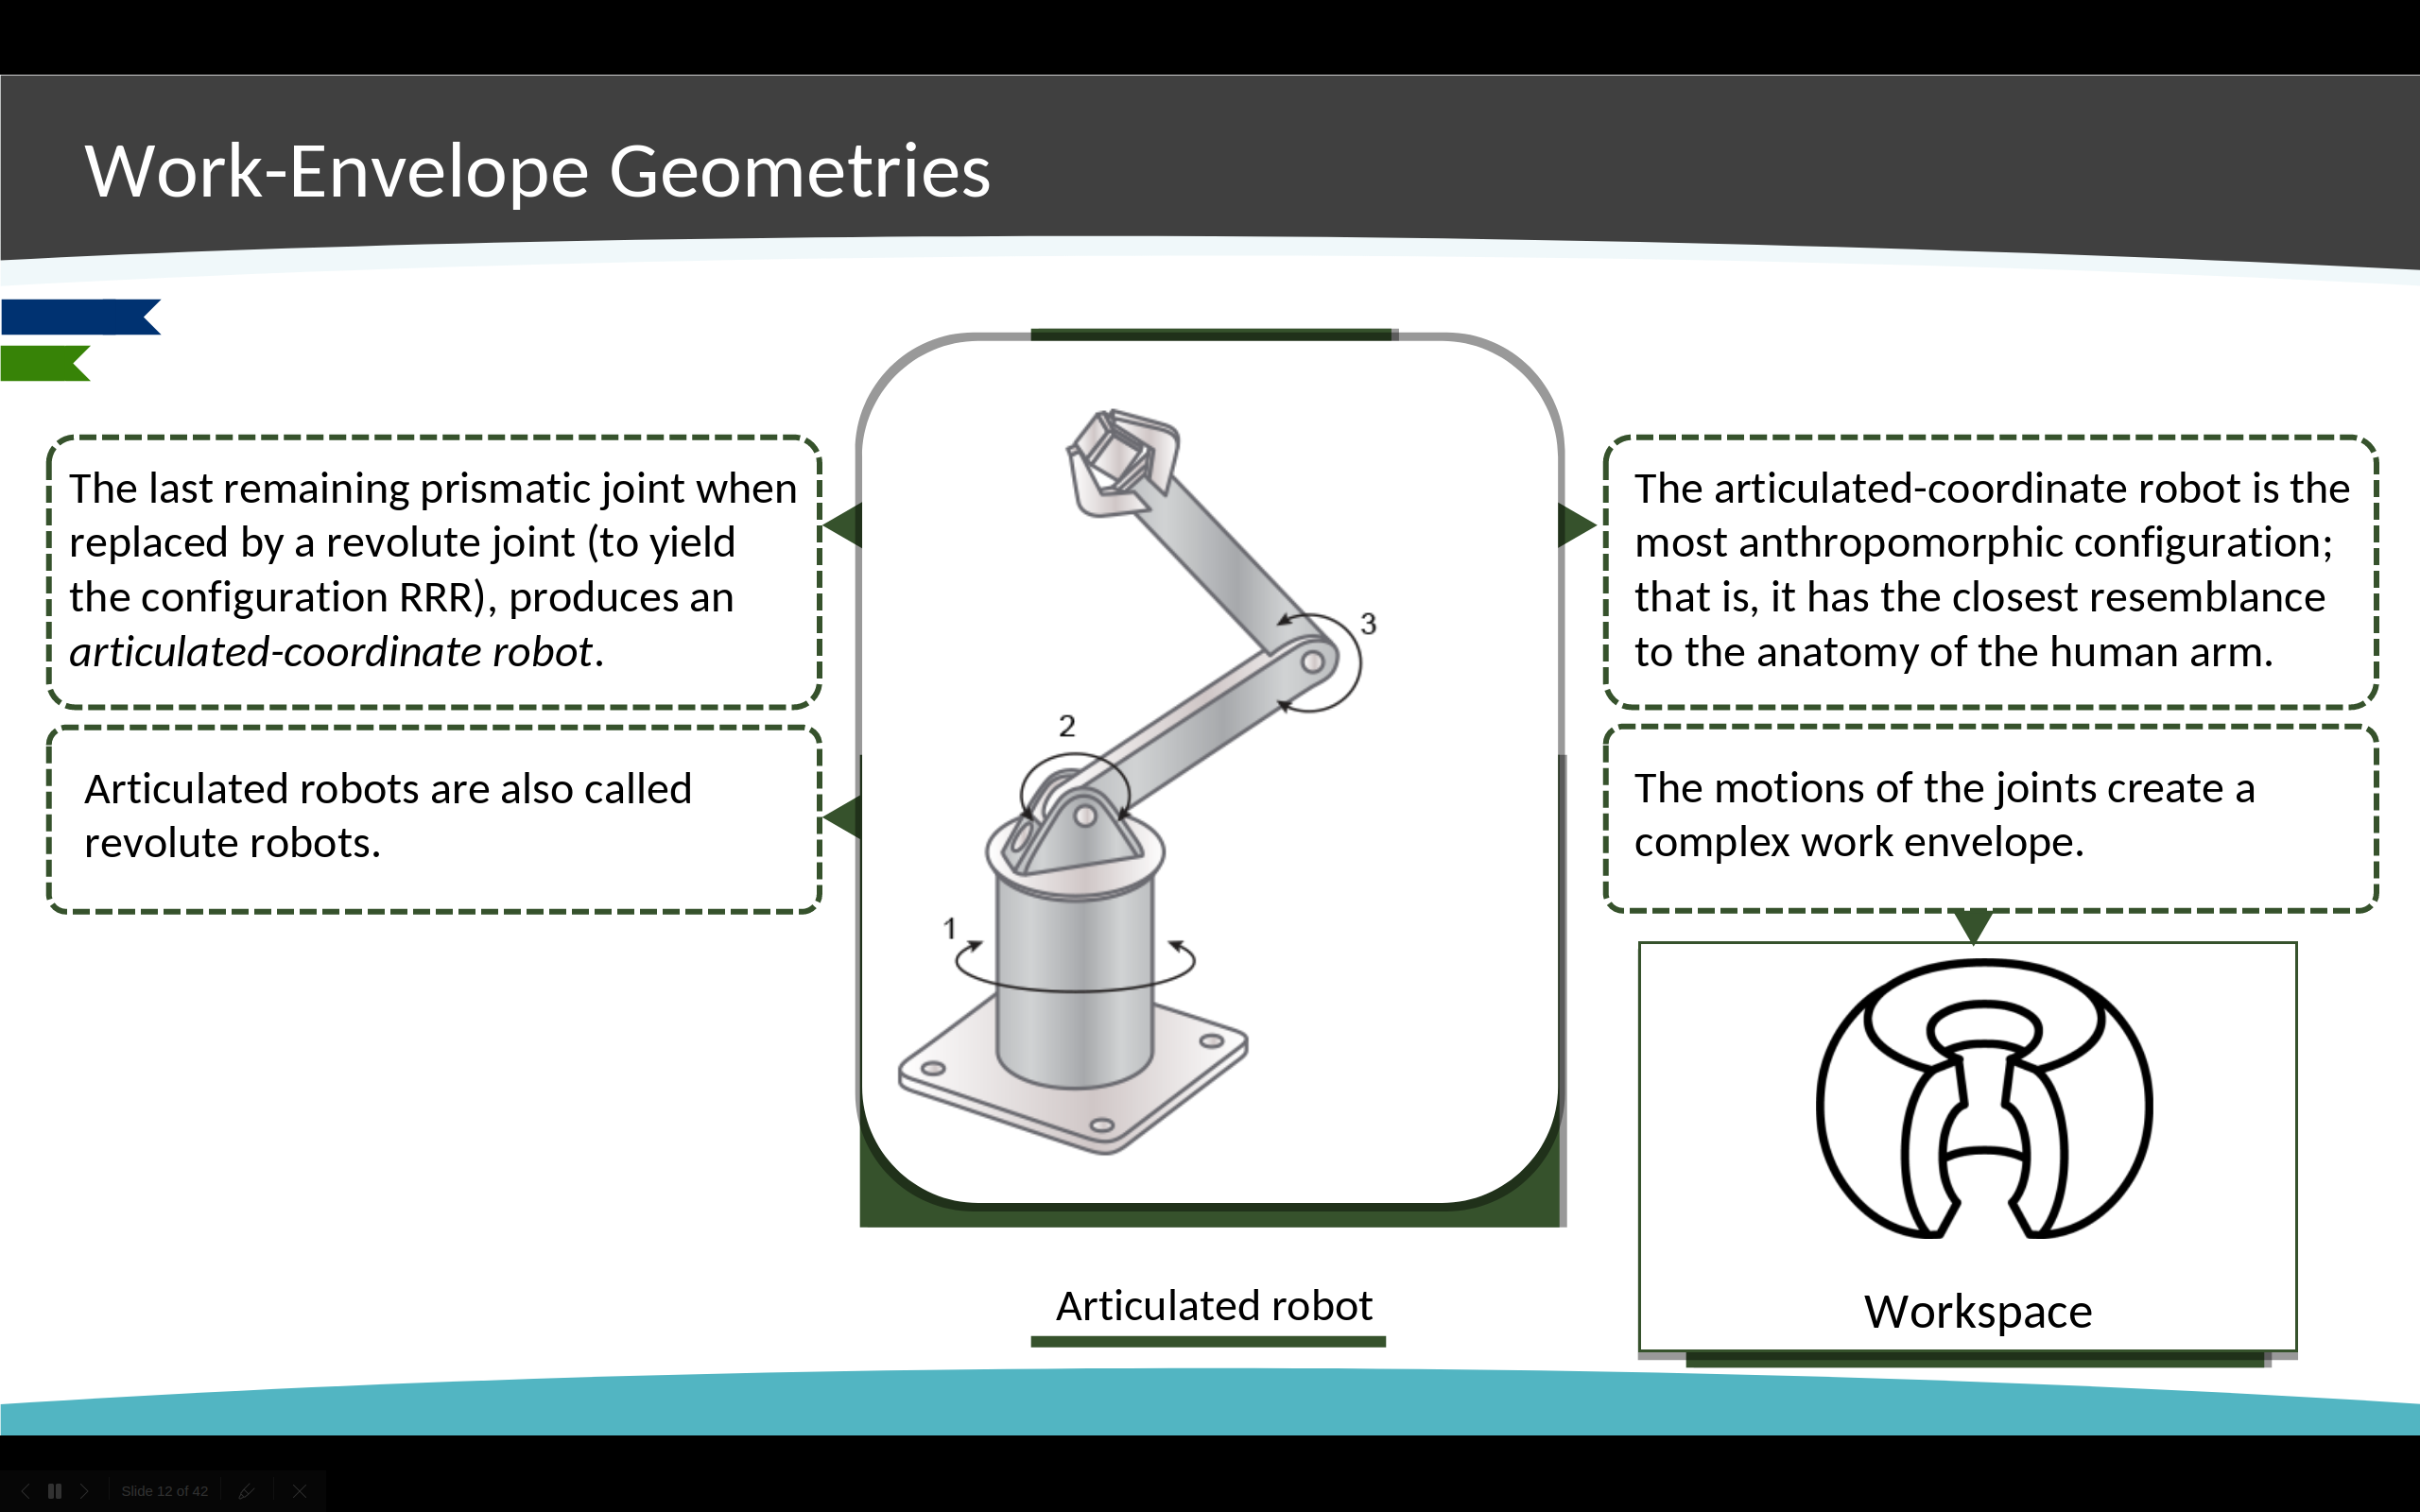
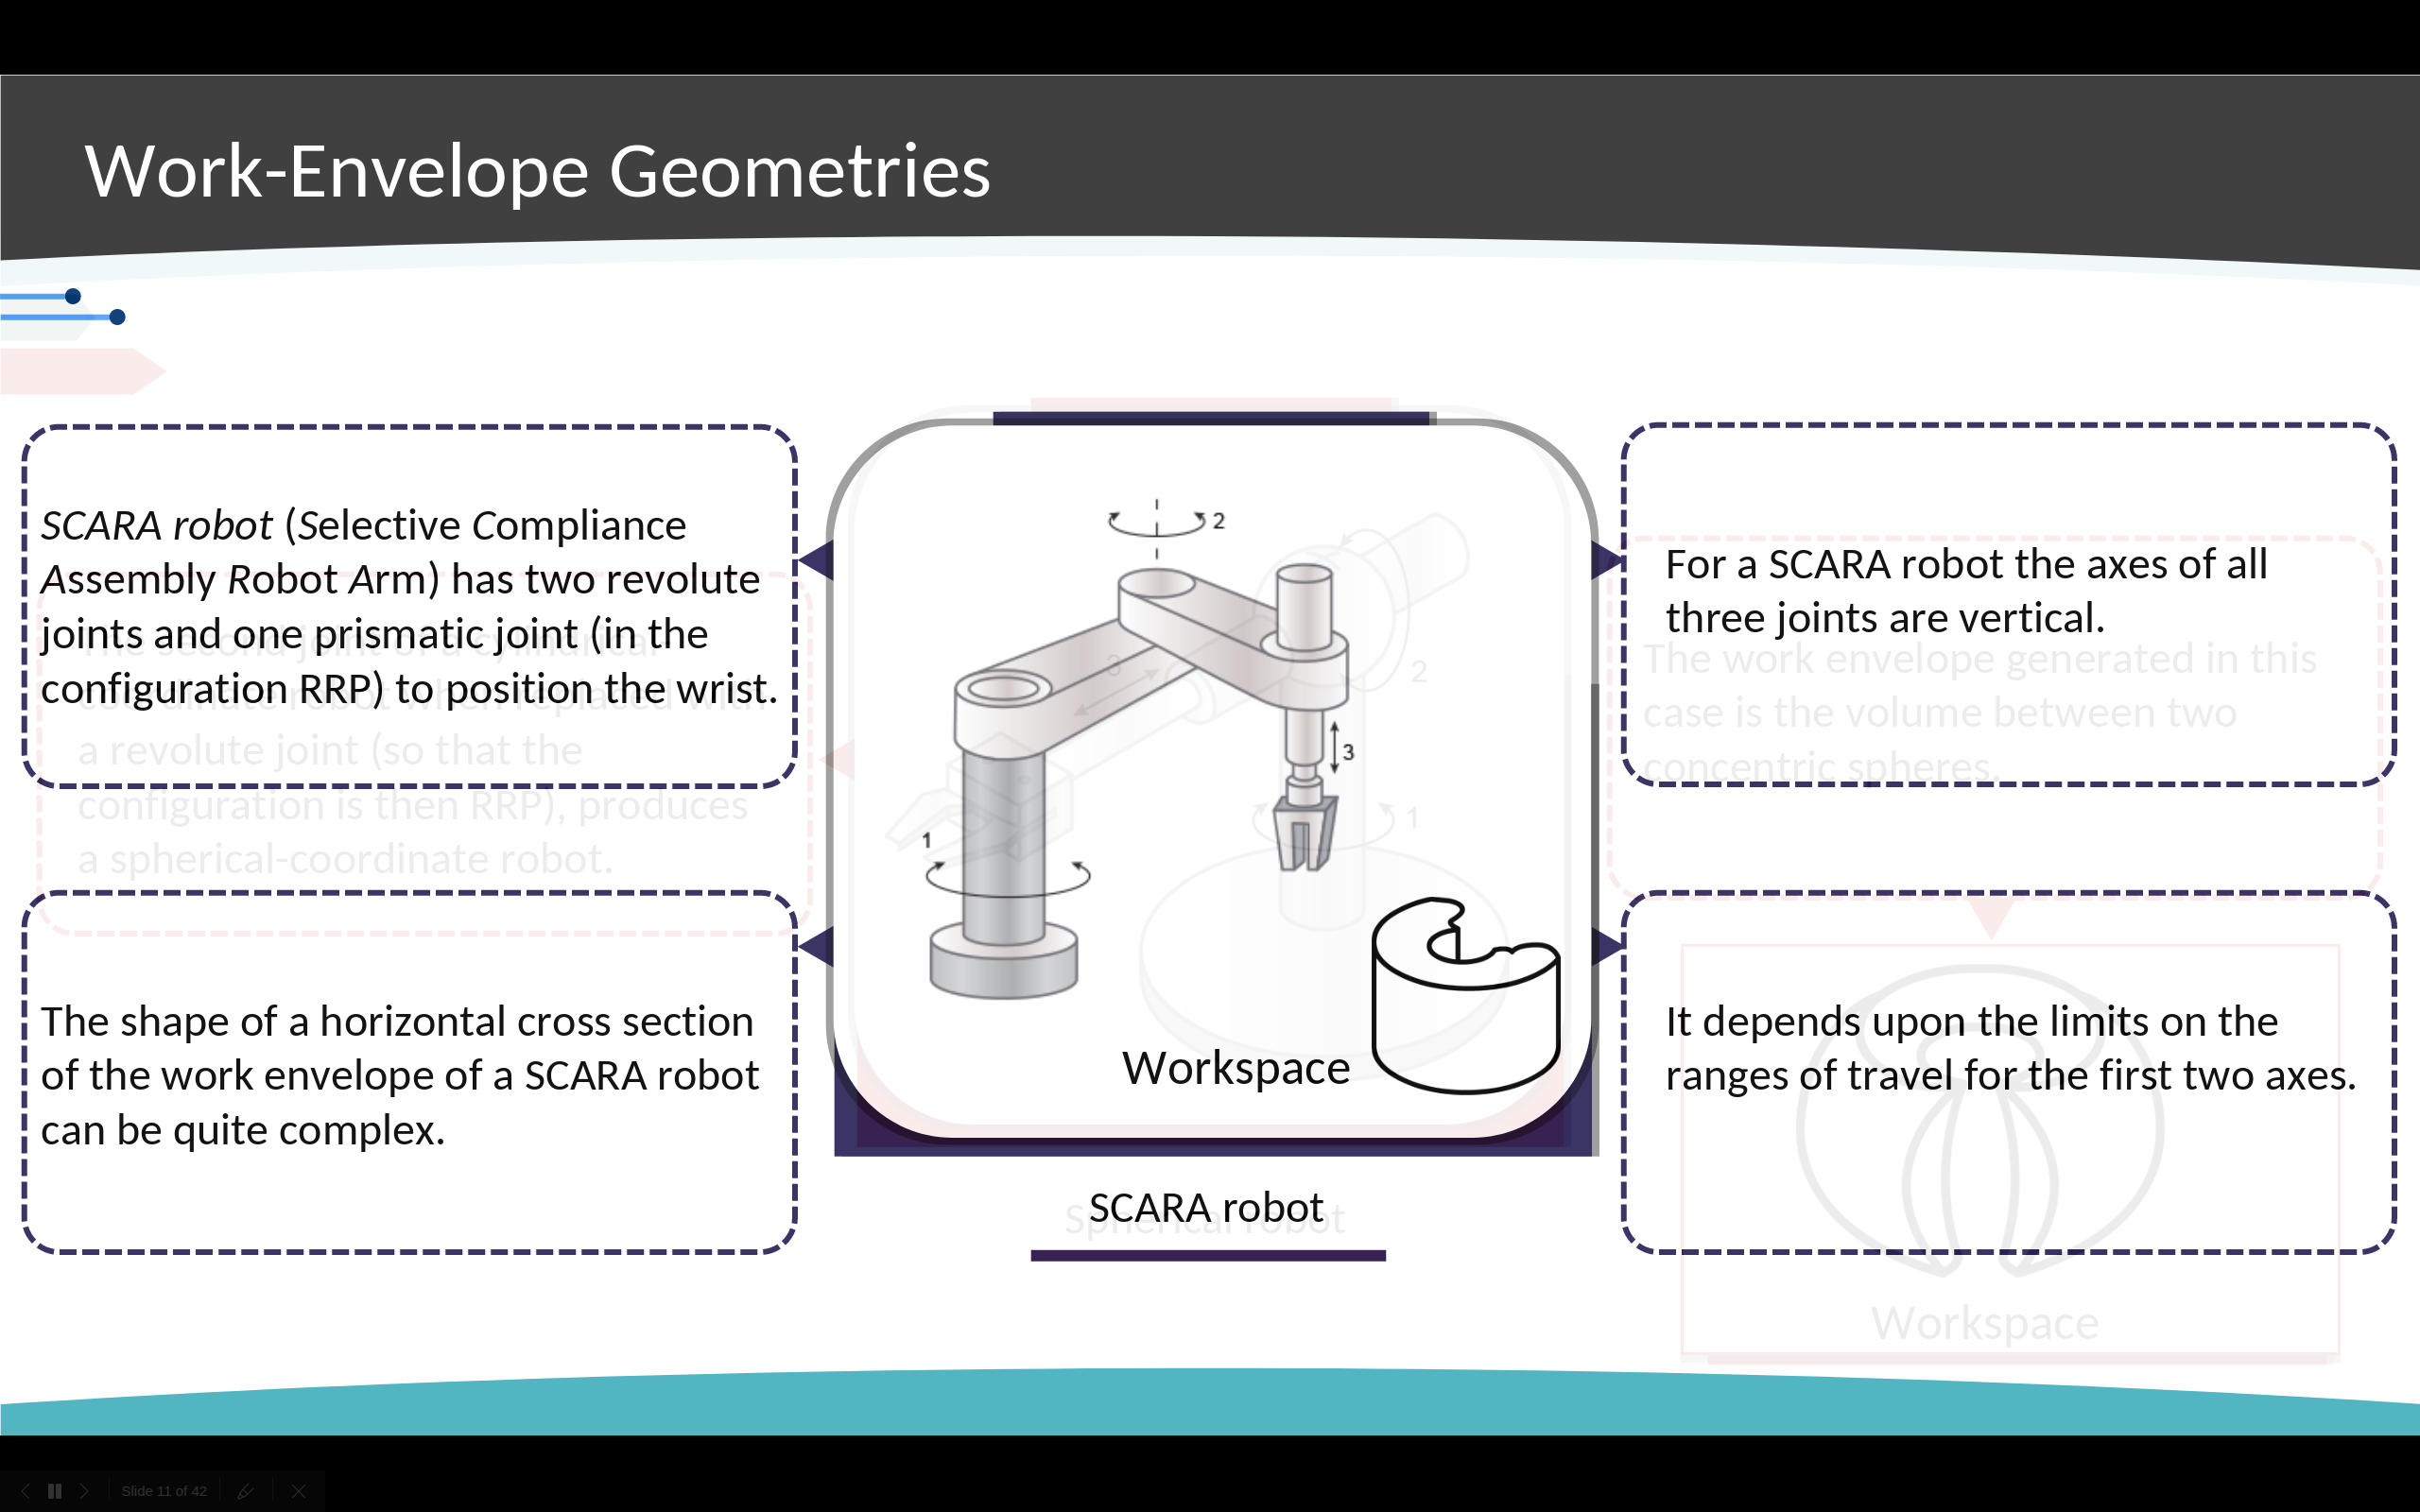
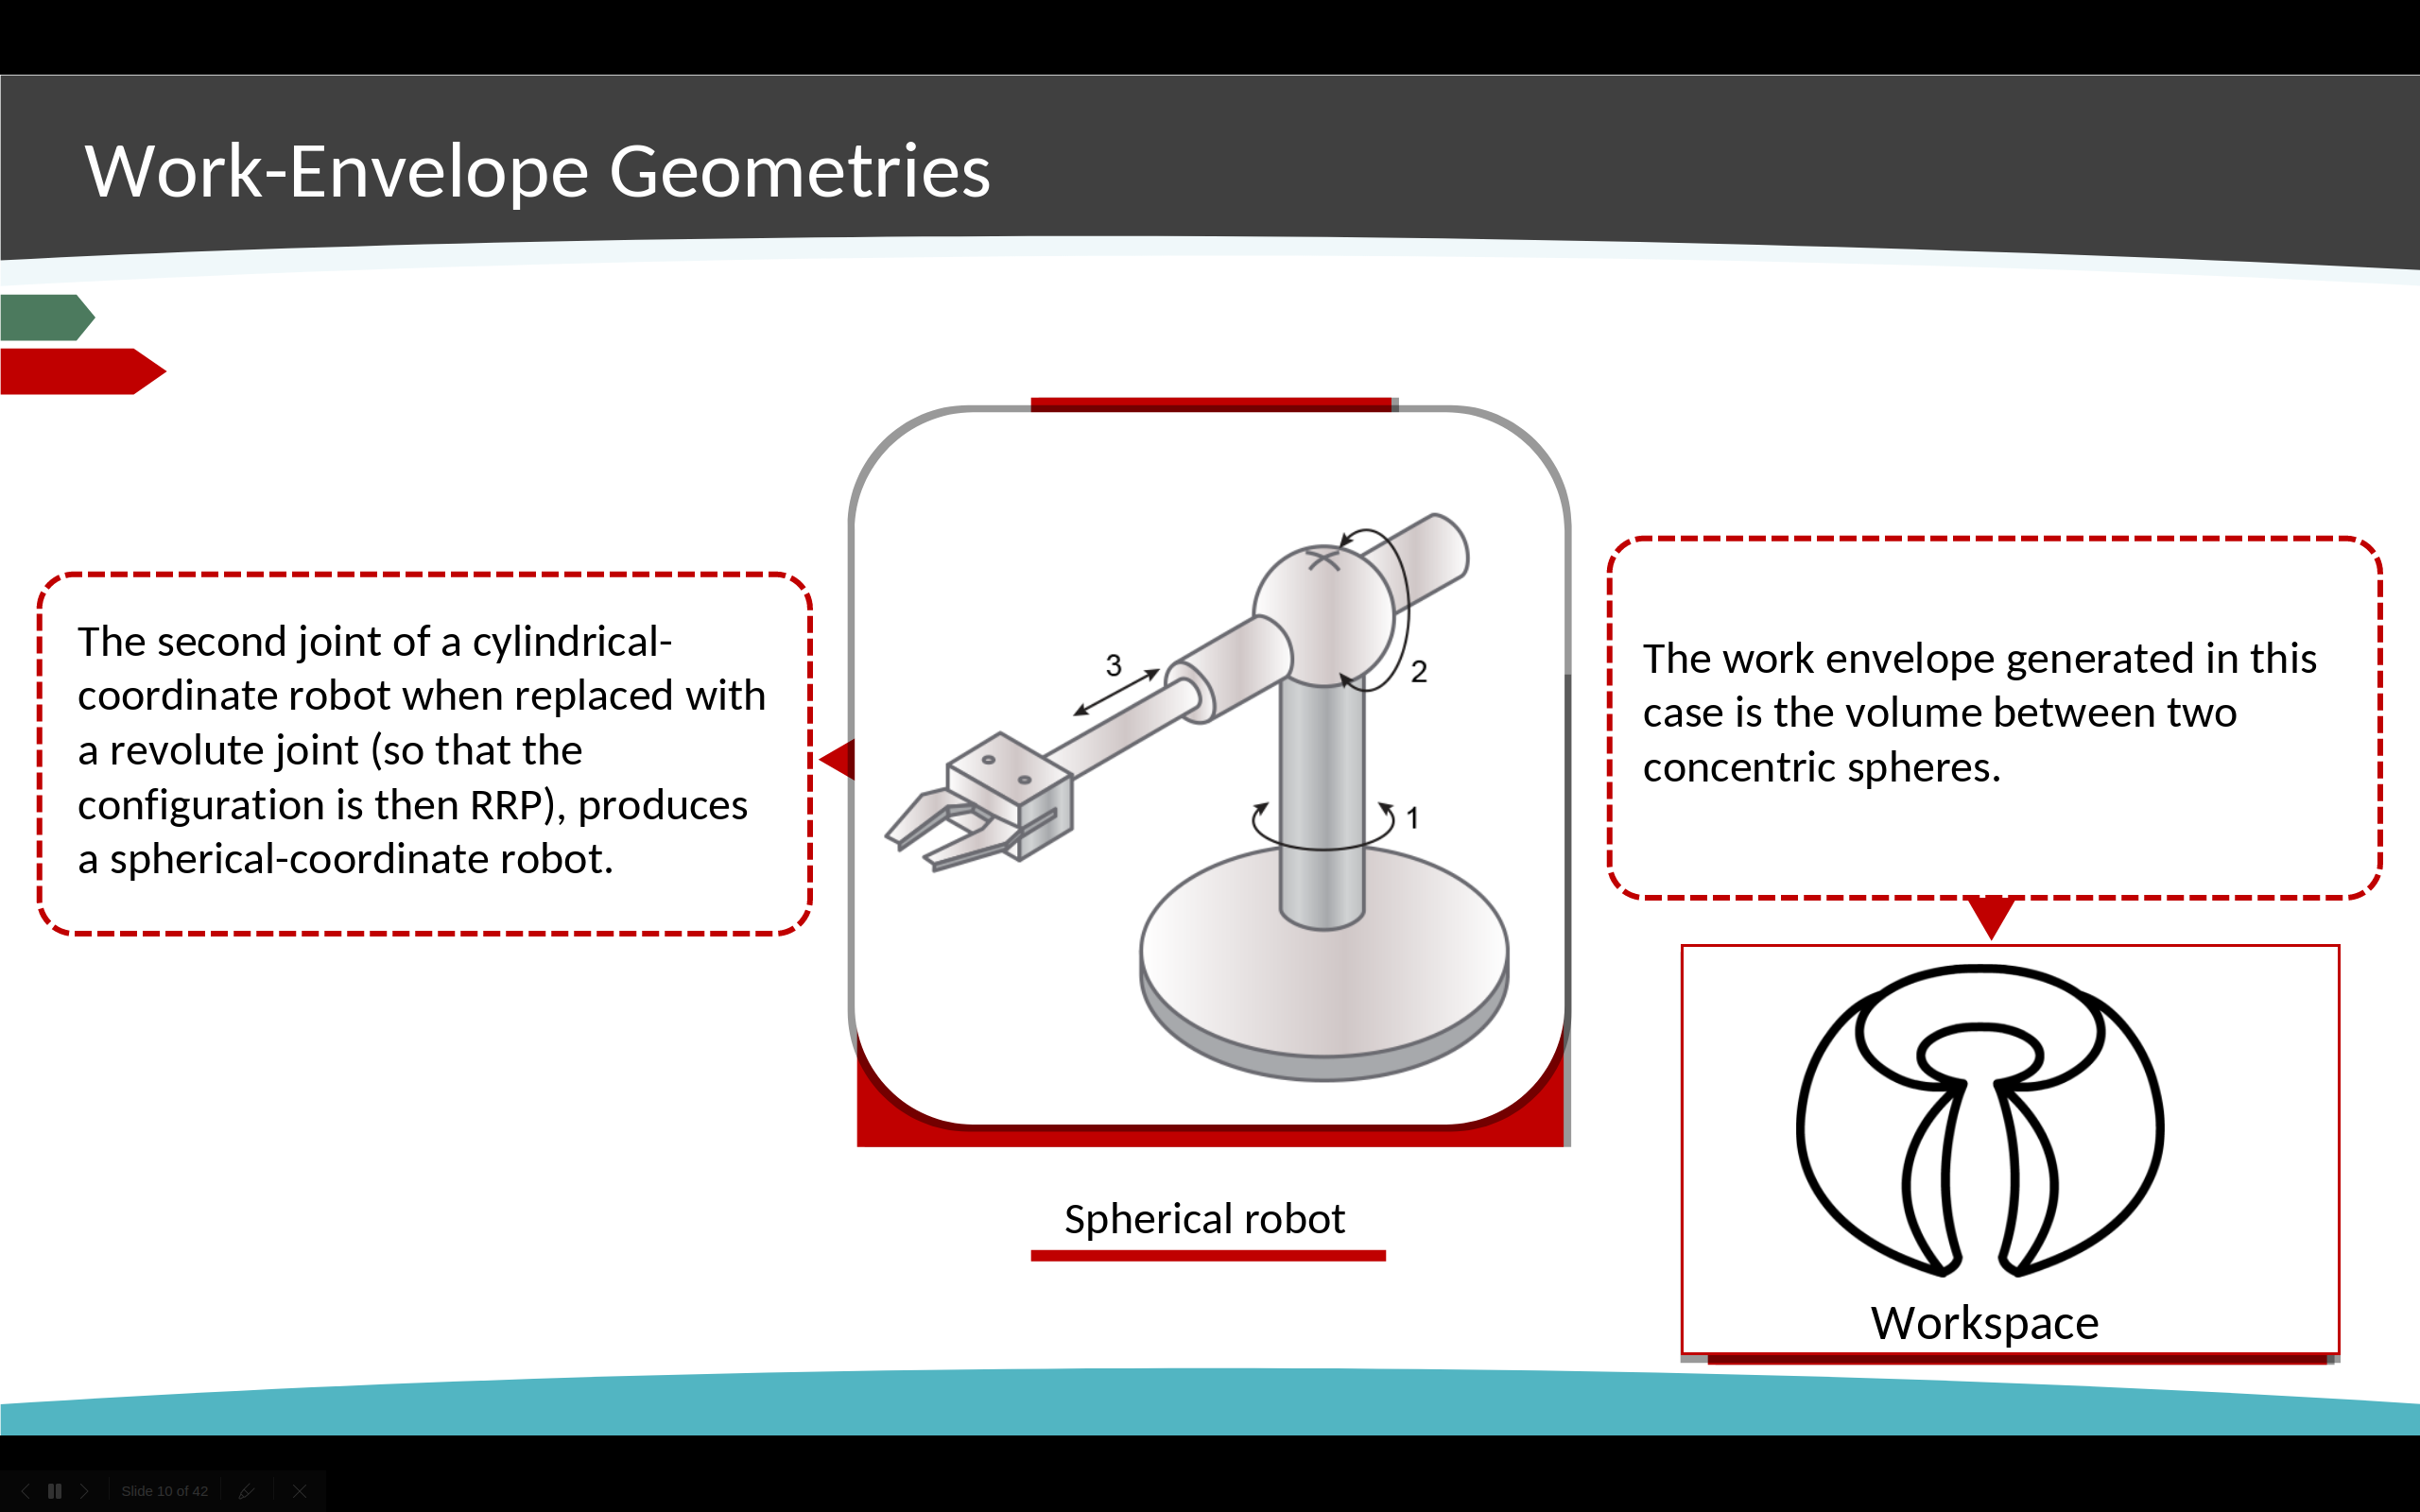
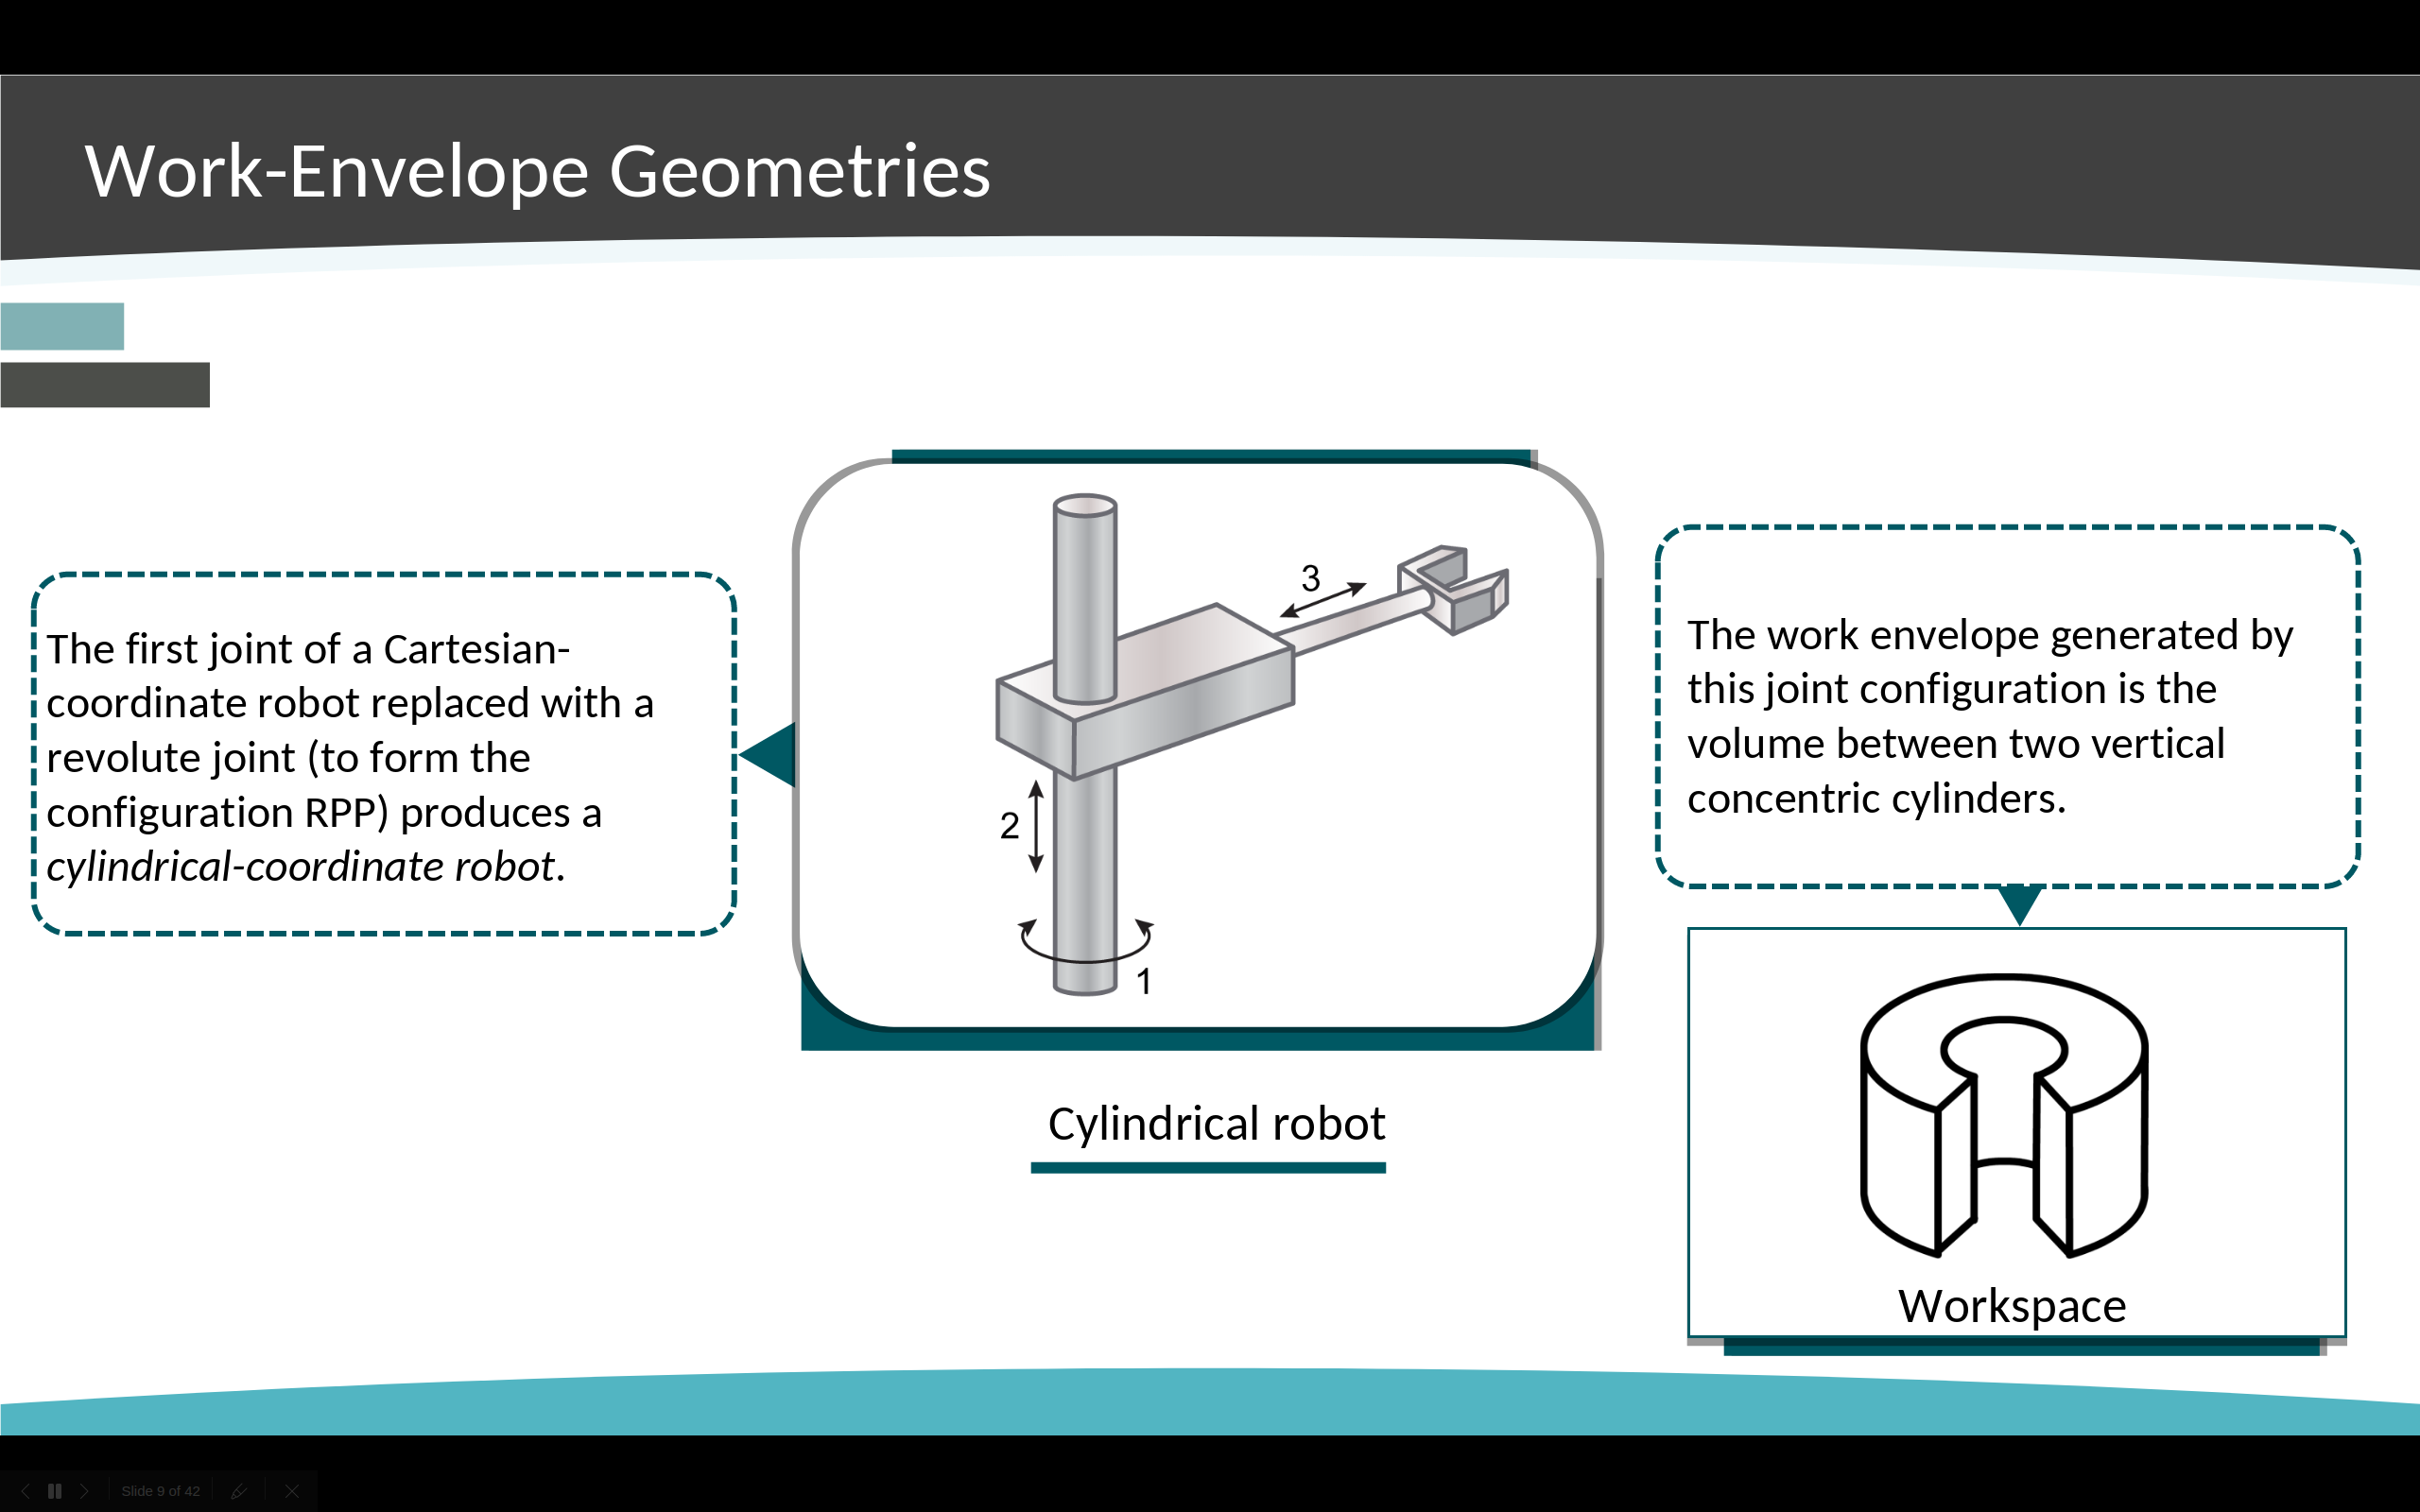
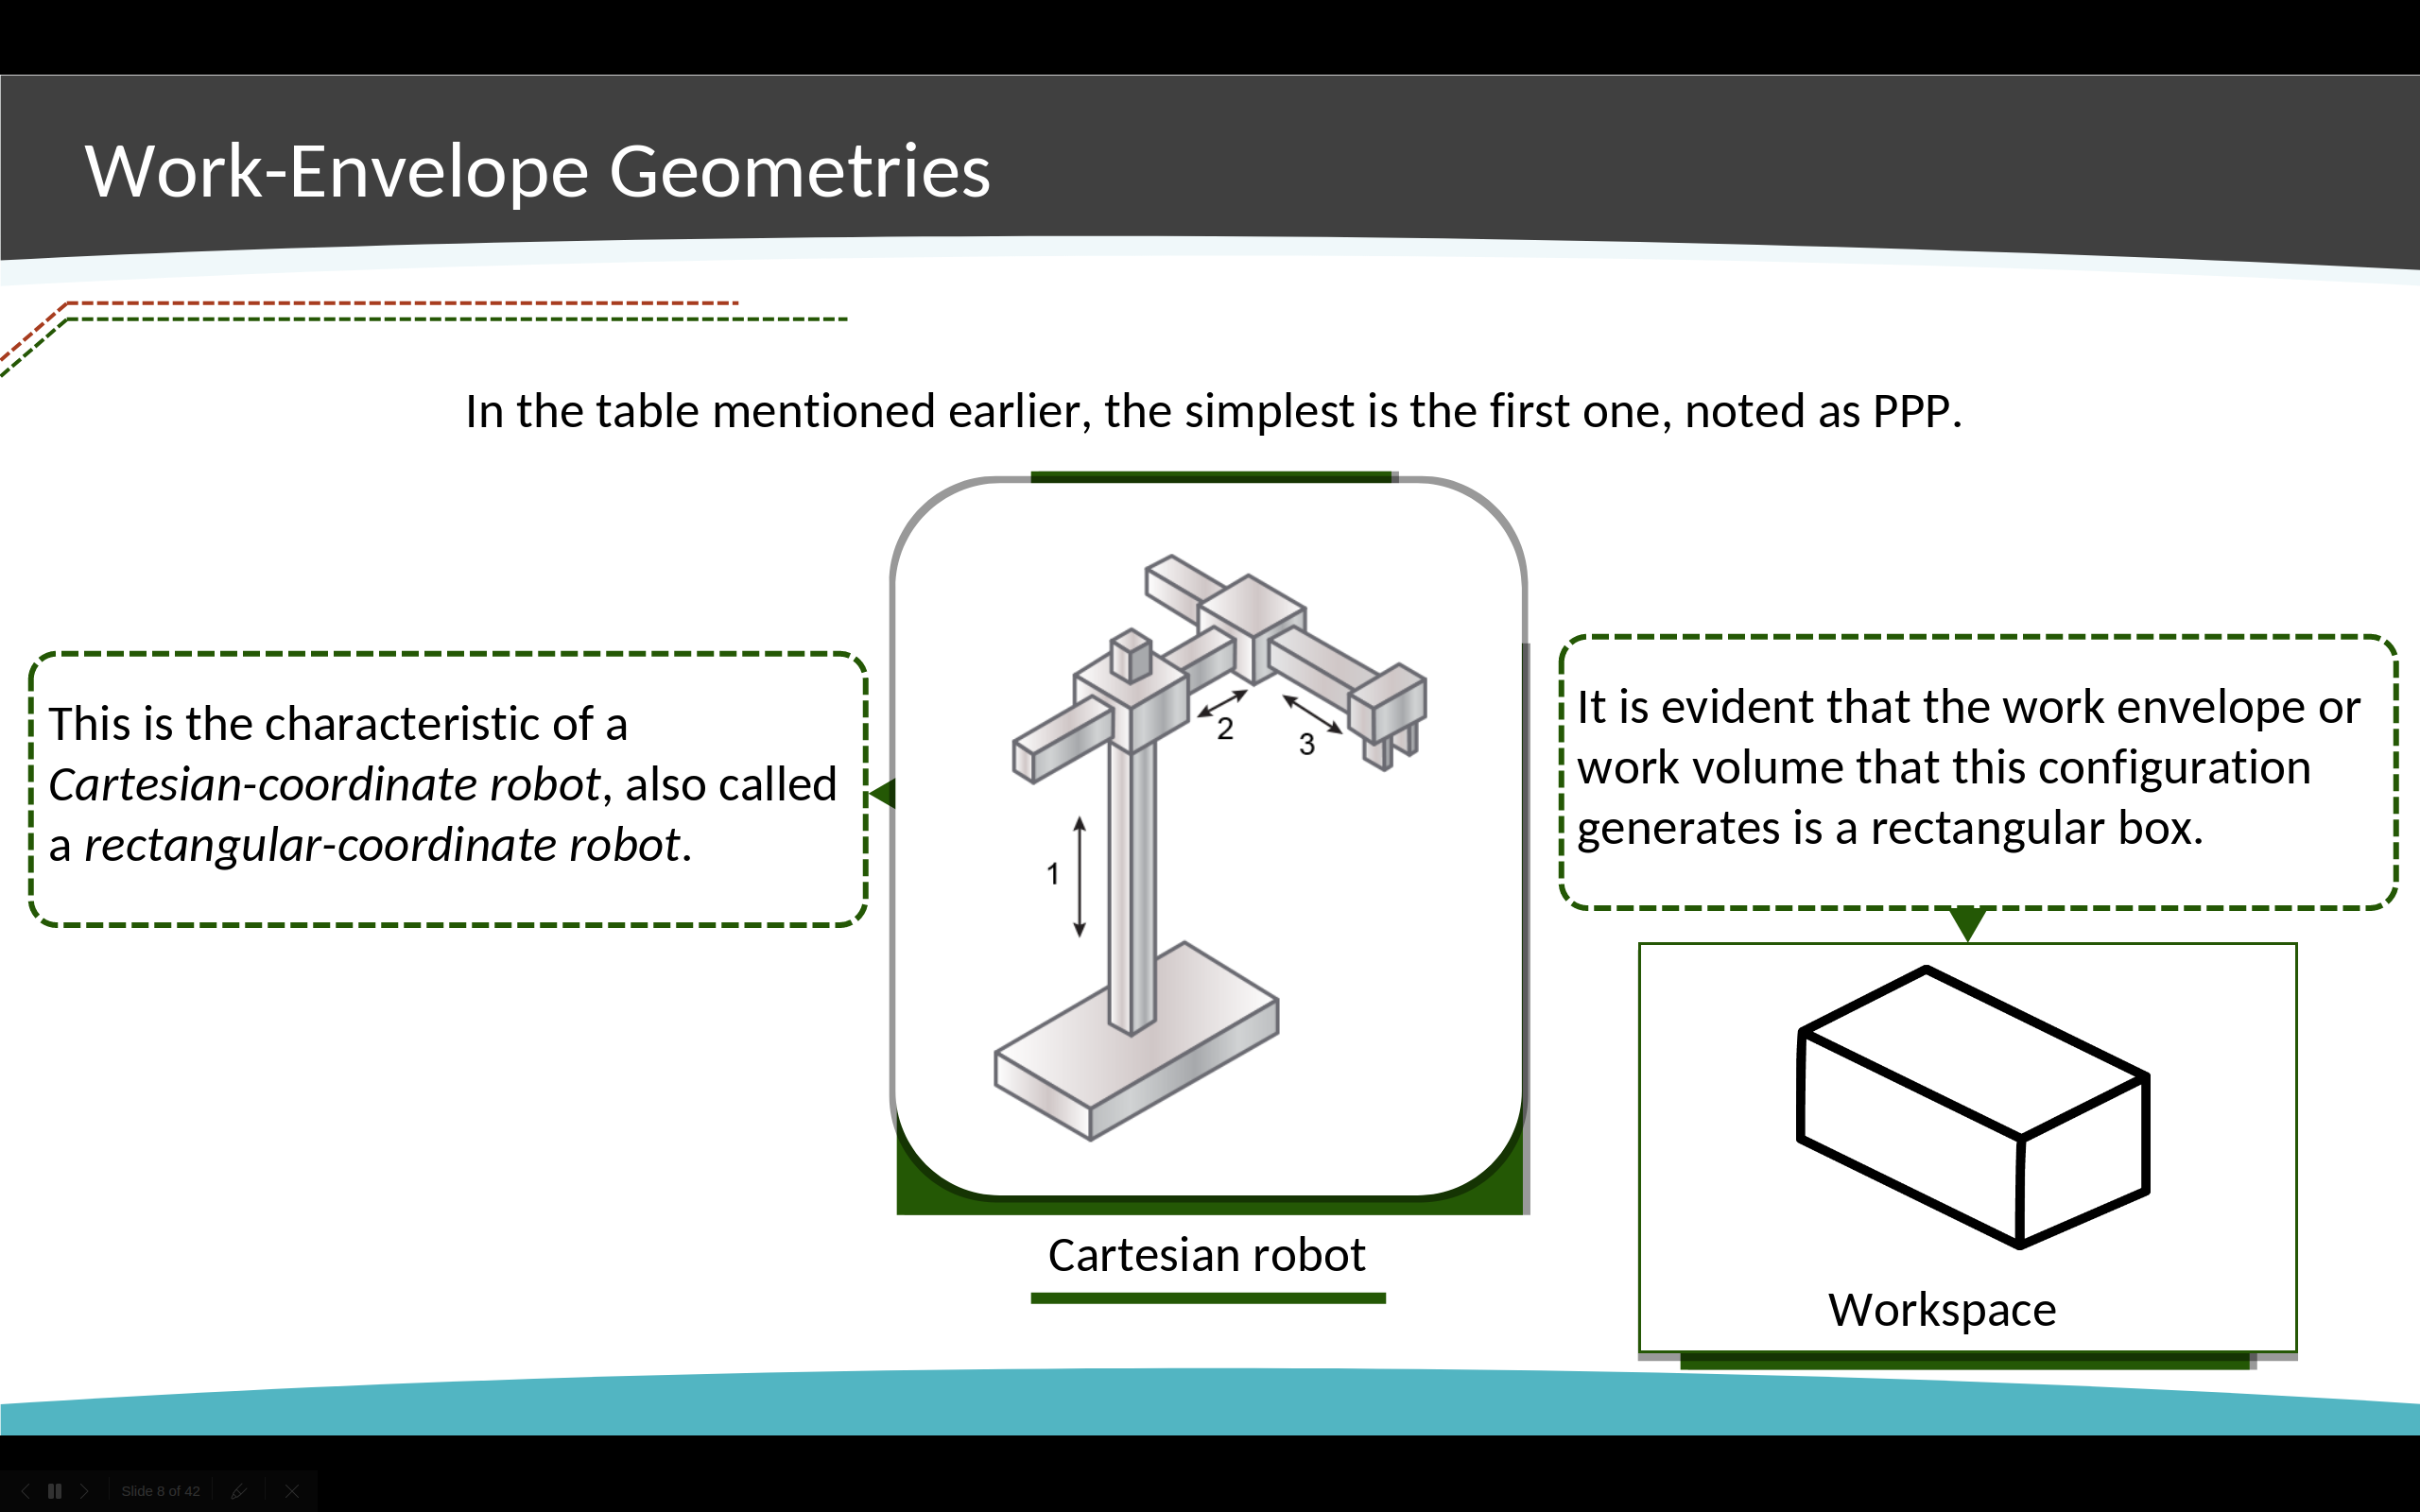
There are 2 types of joints. Revolute (R) exhibits rotation about an axis Prismatic (P) exhibits linear motion along an axis