Besides rotation, there is also translation in the realm of transformations. But with translation, the origin of base frame and mobile frame is no longer shared, unlike rotations. Because of this limitation, a matrix is not able to express translation.
Homogeneuous Coordinate Frames
- q is a point in
- is the orthogonal coordinate frame for
- homogeneuous coordinates of with repsect to are expressed as
- the above is a homogeneuous tranformation matrix
- Note that the represents what we have learnt previously, which is a rotation matrix representing the orientation of mobile frame relative to the base frame
- is the translation vector that represents the position of origin of mobile frame relative to origin at fixed frame
Homogenuous Rotation
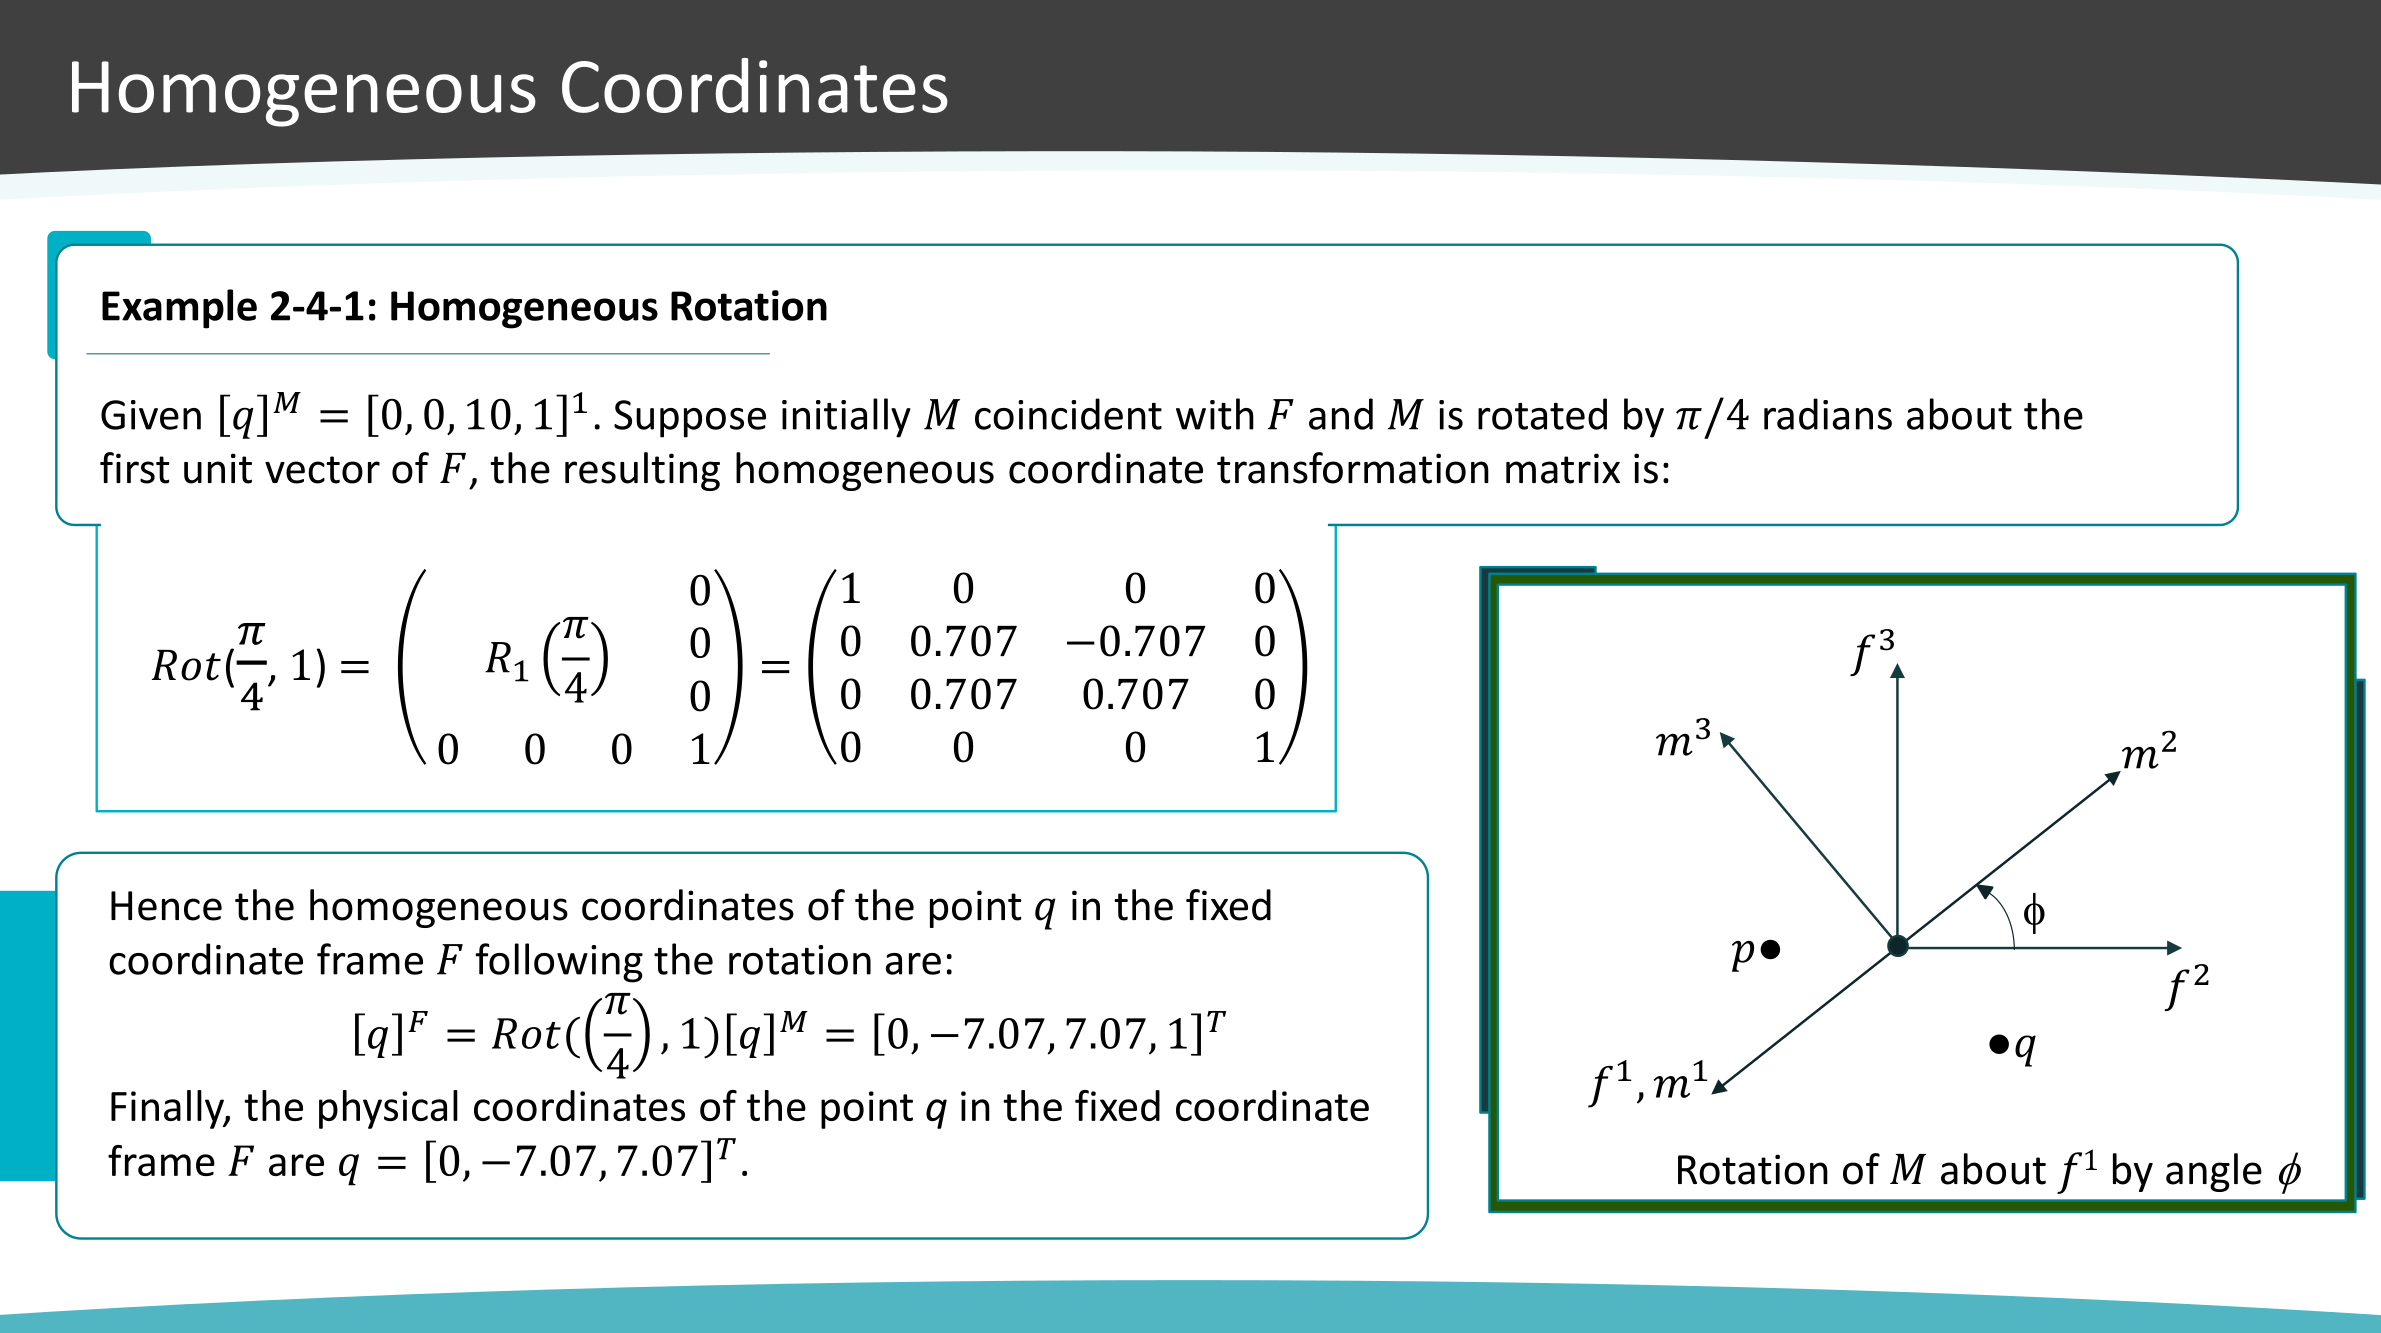
The homogeneuous transformation matrix can be expressed as such when there is only rotation involved:
- this is essentially the same as 's structure, but we just let
- represents the angle that is rotated about the th unit vector of
Worked Example
Homogeneuous Translation
- this is the representation of homogeneous translation, without rotation
- and are initially coicident
- we translate the origin by an amount along the th unit vector of
Assuming a mobile frame moved translation from initial position at . We can express homogeneuous coordinate of point relative to reference frame as such: