When a number of fundamental rotation matrix are multiplied together, the product matrix represents a sequence of rotations about the unit vectors. This multiple rotations is a form of composite rotations.
Step by step
Start by setting the cumulative rotation matrix to an identity matrix:
If the next rotation is by an angle about the -th axis of the fixed frame , update by pre-multiplying:
If the next rotation is by an angle about the -th axis of the mobile frame , update by post-multiplying:
- basically if the rotation is about the fixed frame, we pre-mulitply, which is adding the rotation in front of our initial identity
- for rotation about its own mobile frame , we post-multiply, which is adding the rotation behind the initial identity
Worked Example
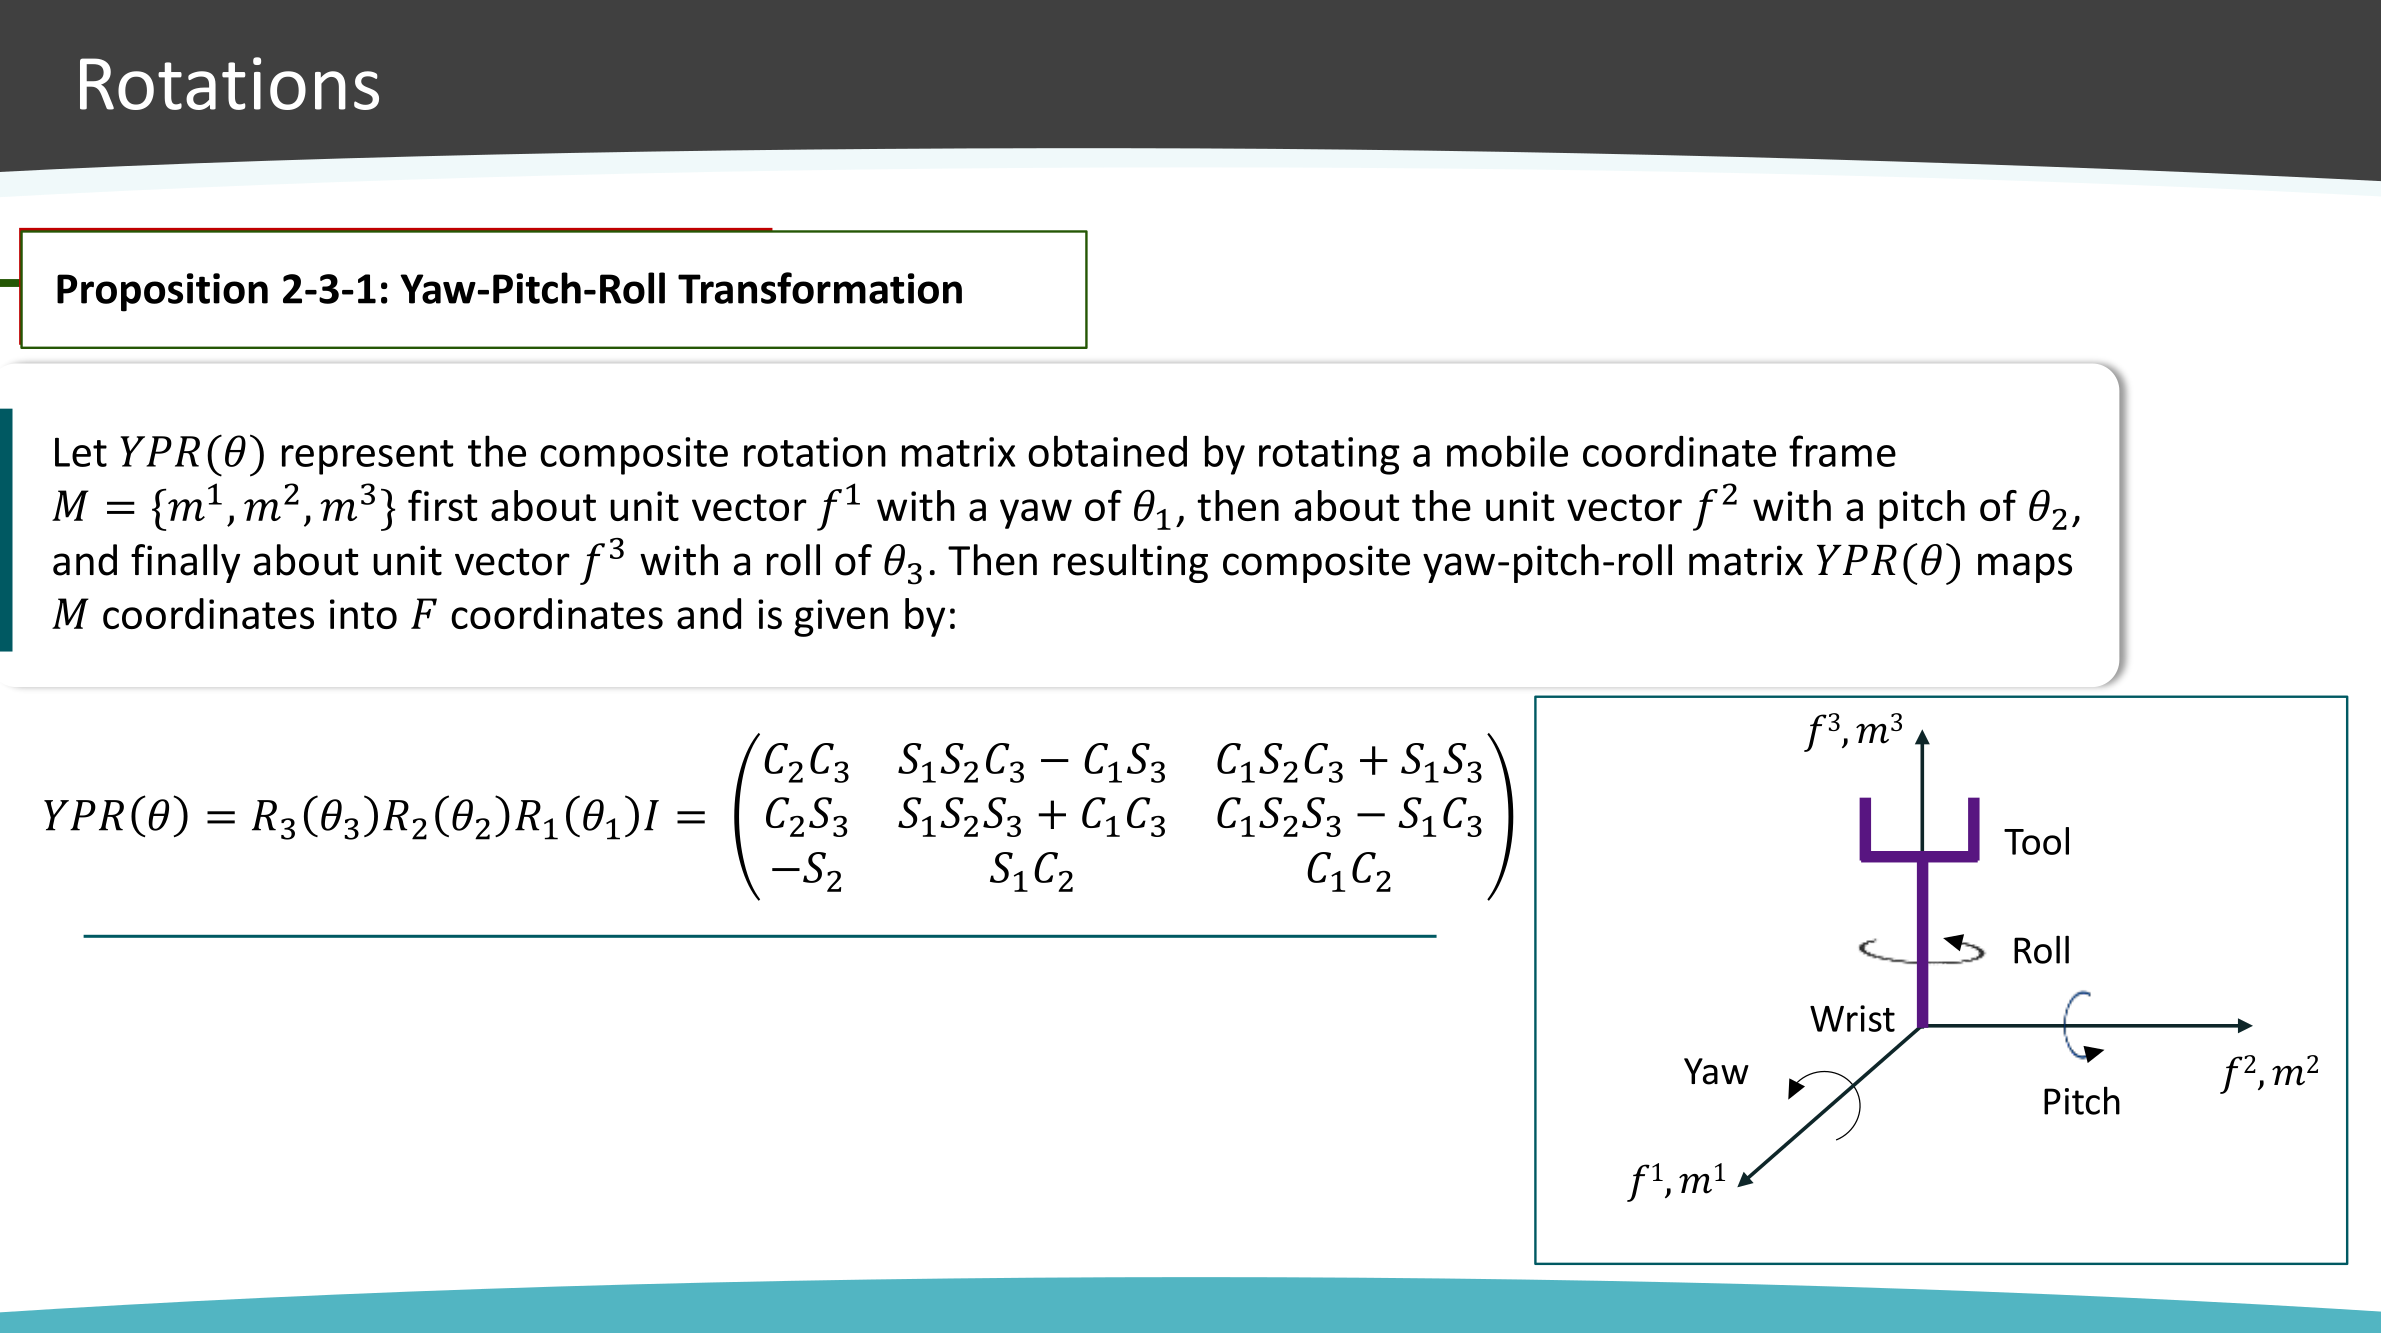
Tip
Yaw is for Axis 1
Pitch is for Axis 2
Roll is for Axis 3
- Think of it as "You Practice Robotics!", where its 1, ,2, 3 respectively