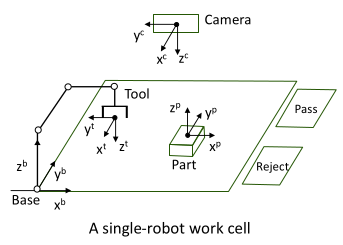
This image shows a single robot work cell.
represents the pose of the part as seen by the camera. represents the pose of the robot's base as seen by the camera.
Suppose:
then,
where the position of the part relative to the base frame is . Moreover, the 3 axes of the part's frame points to the same directions as the base frame, since the rotation submatrix is .
To determine rotation matrix if the robot is supposed to reach down and pick up the part directly from above,
With respect to the base coordinates, this corresponds to . To grip to object from the front and back, there needs to be a sliding vector of , and to complete the orthogonal coordinate frame, it is a requirement that . Therefore, there are two possible solutions for the rotation matrix , one being:
Now we can put the position and orientation together to develop the tool configuration needed to grasp the part.