Introduction
An incremental encoder only counts changes in angle. It does not know the start angle when the robot is first energised. So the robot must calibrate (initialise) each joint at power up.
Absolute position = initial position + relative position.
How it works (with an index pulse)
Add a zero reference channel to the encoder disk. It has one line and gives a single index pulse for each revolution.
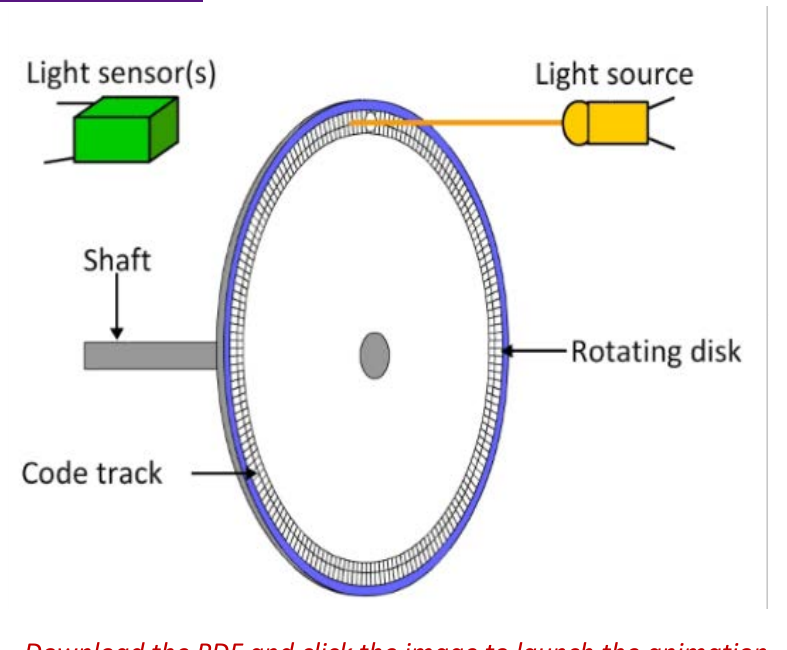
- At power up, each joint moves in a set direction to a mechanical end stop
- The actuator reverses and moves until the first index pulse occurs
- The counter is set to zero at this point, which is the calibration point
- The absolute position comes from the encoder count and the number of index pulses
How it works (without an index pulse)
- At power up, each axis moves until it reaches its mechanical end stop
- The encoder count is noted and the actuator reverses
- The motion stops after a set number of encoder counts
- The count is initialised