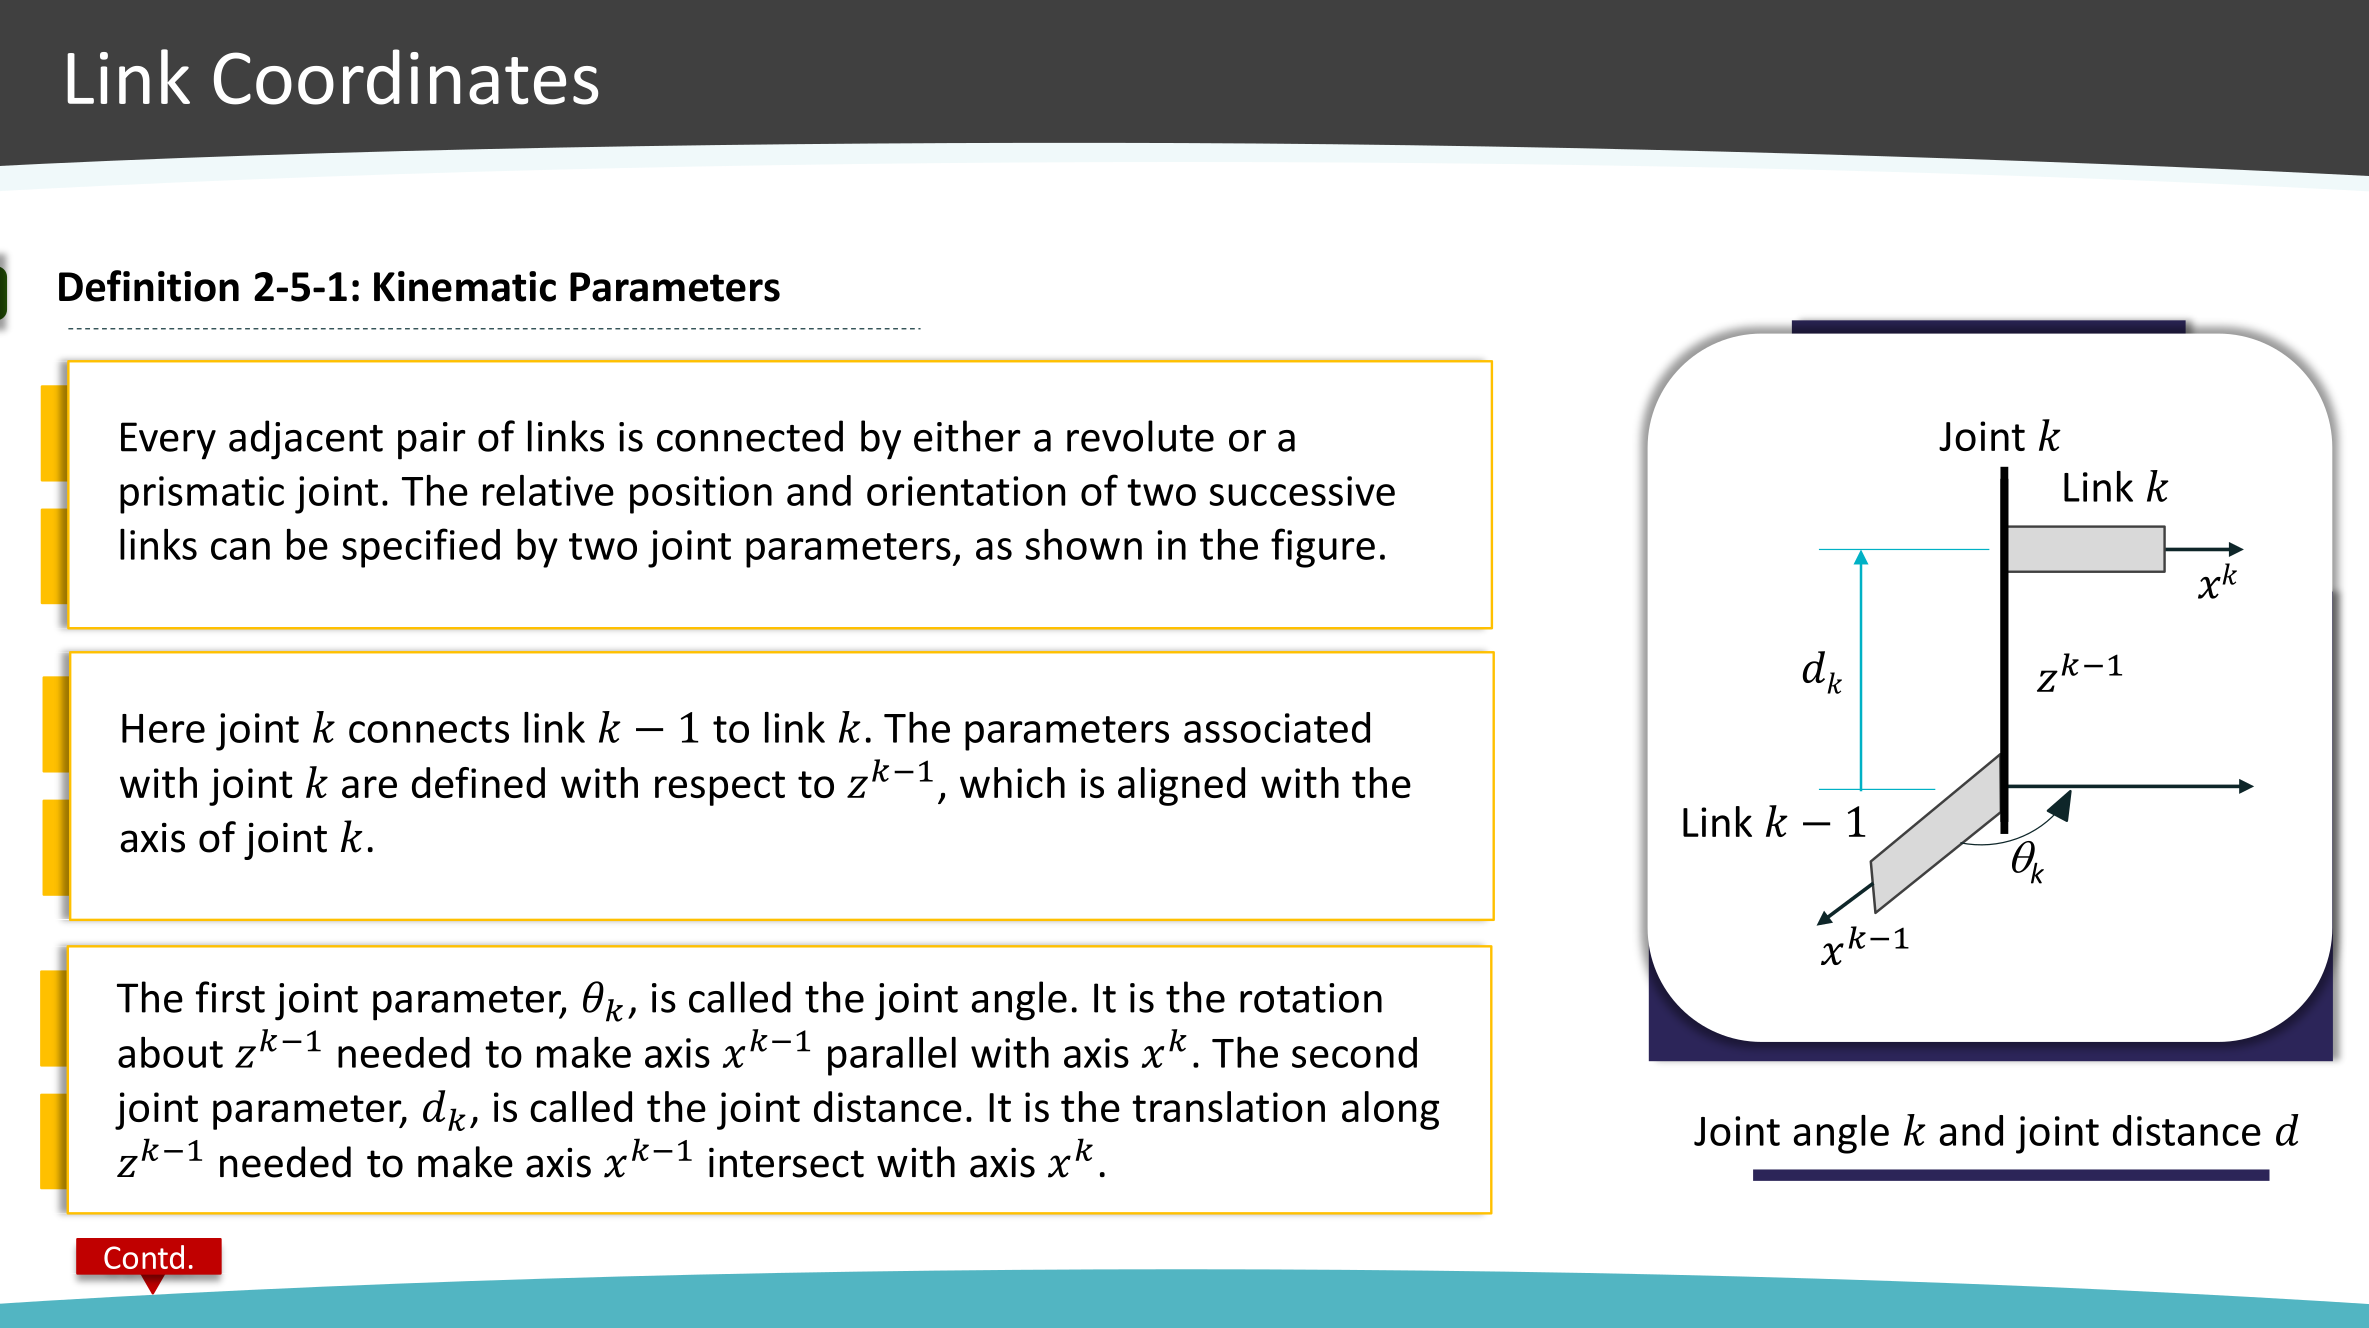
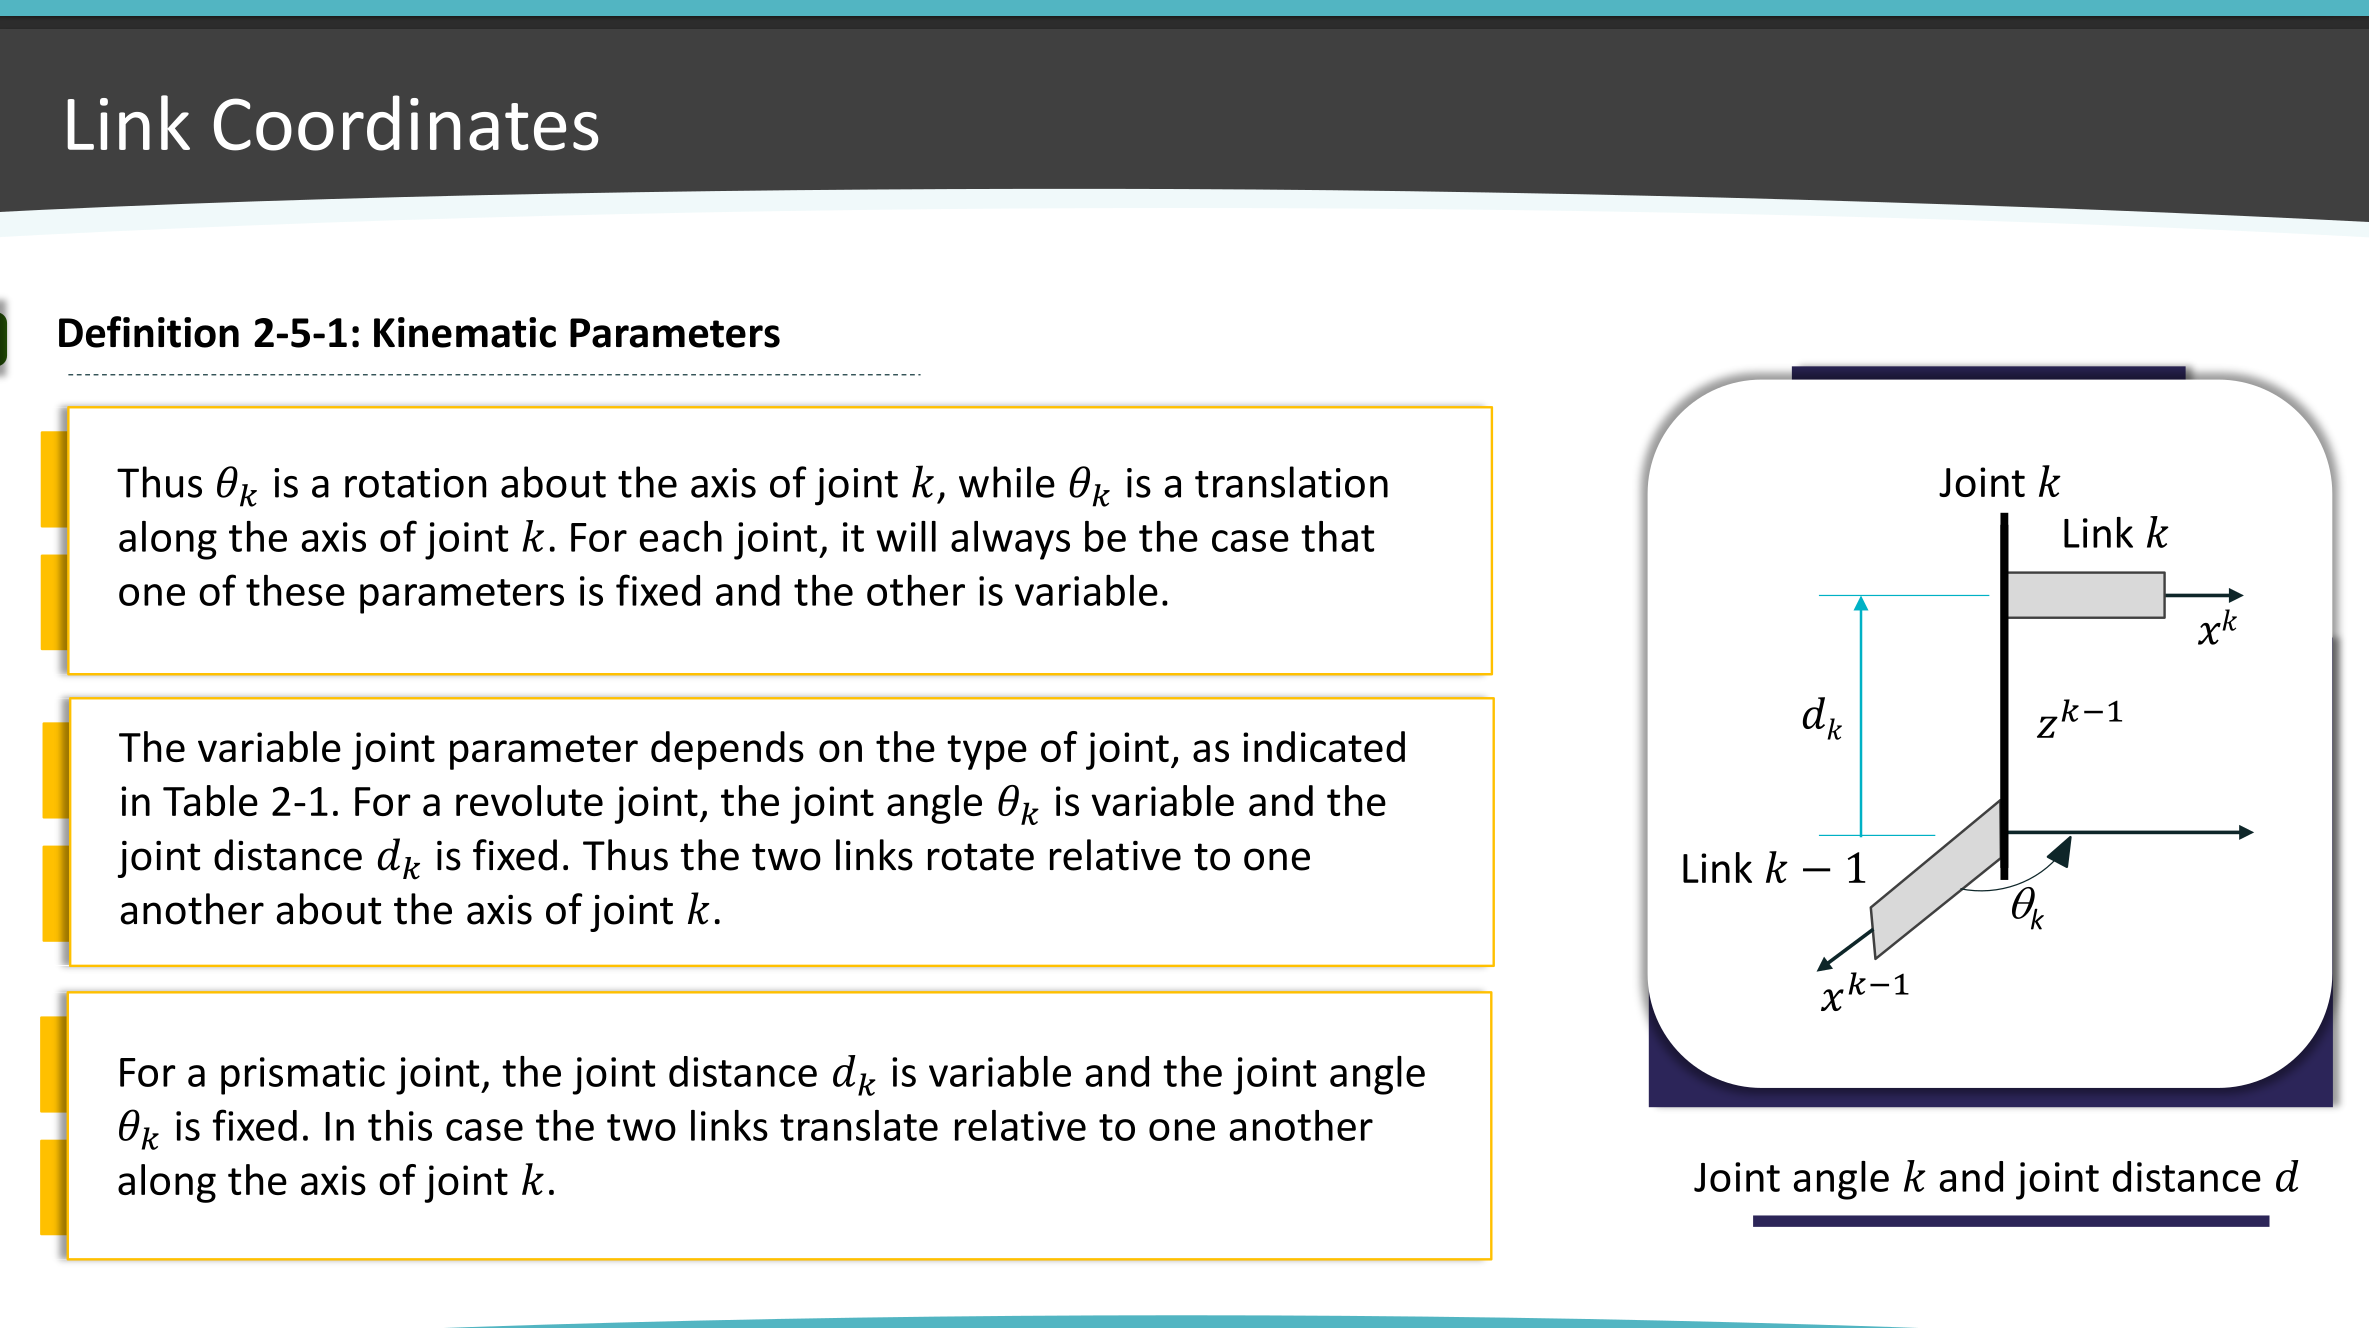
The 2 slides above introduces the 2 D-H parameters, namely the joint distance and joint angle, . Understanding the diagram, we have a center joint , that connects 2 links ( and ). The joint'a axis, is defined, along with the link's own axes, and .
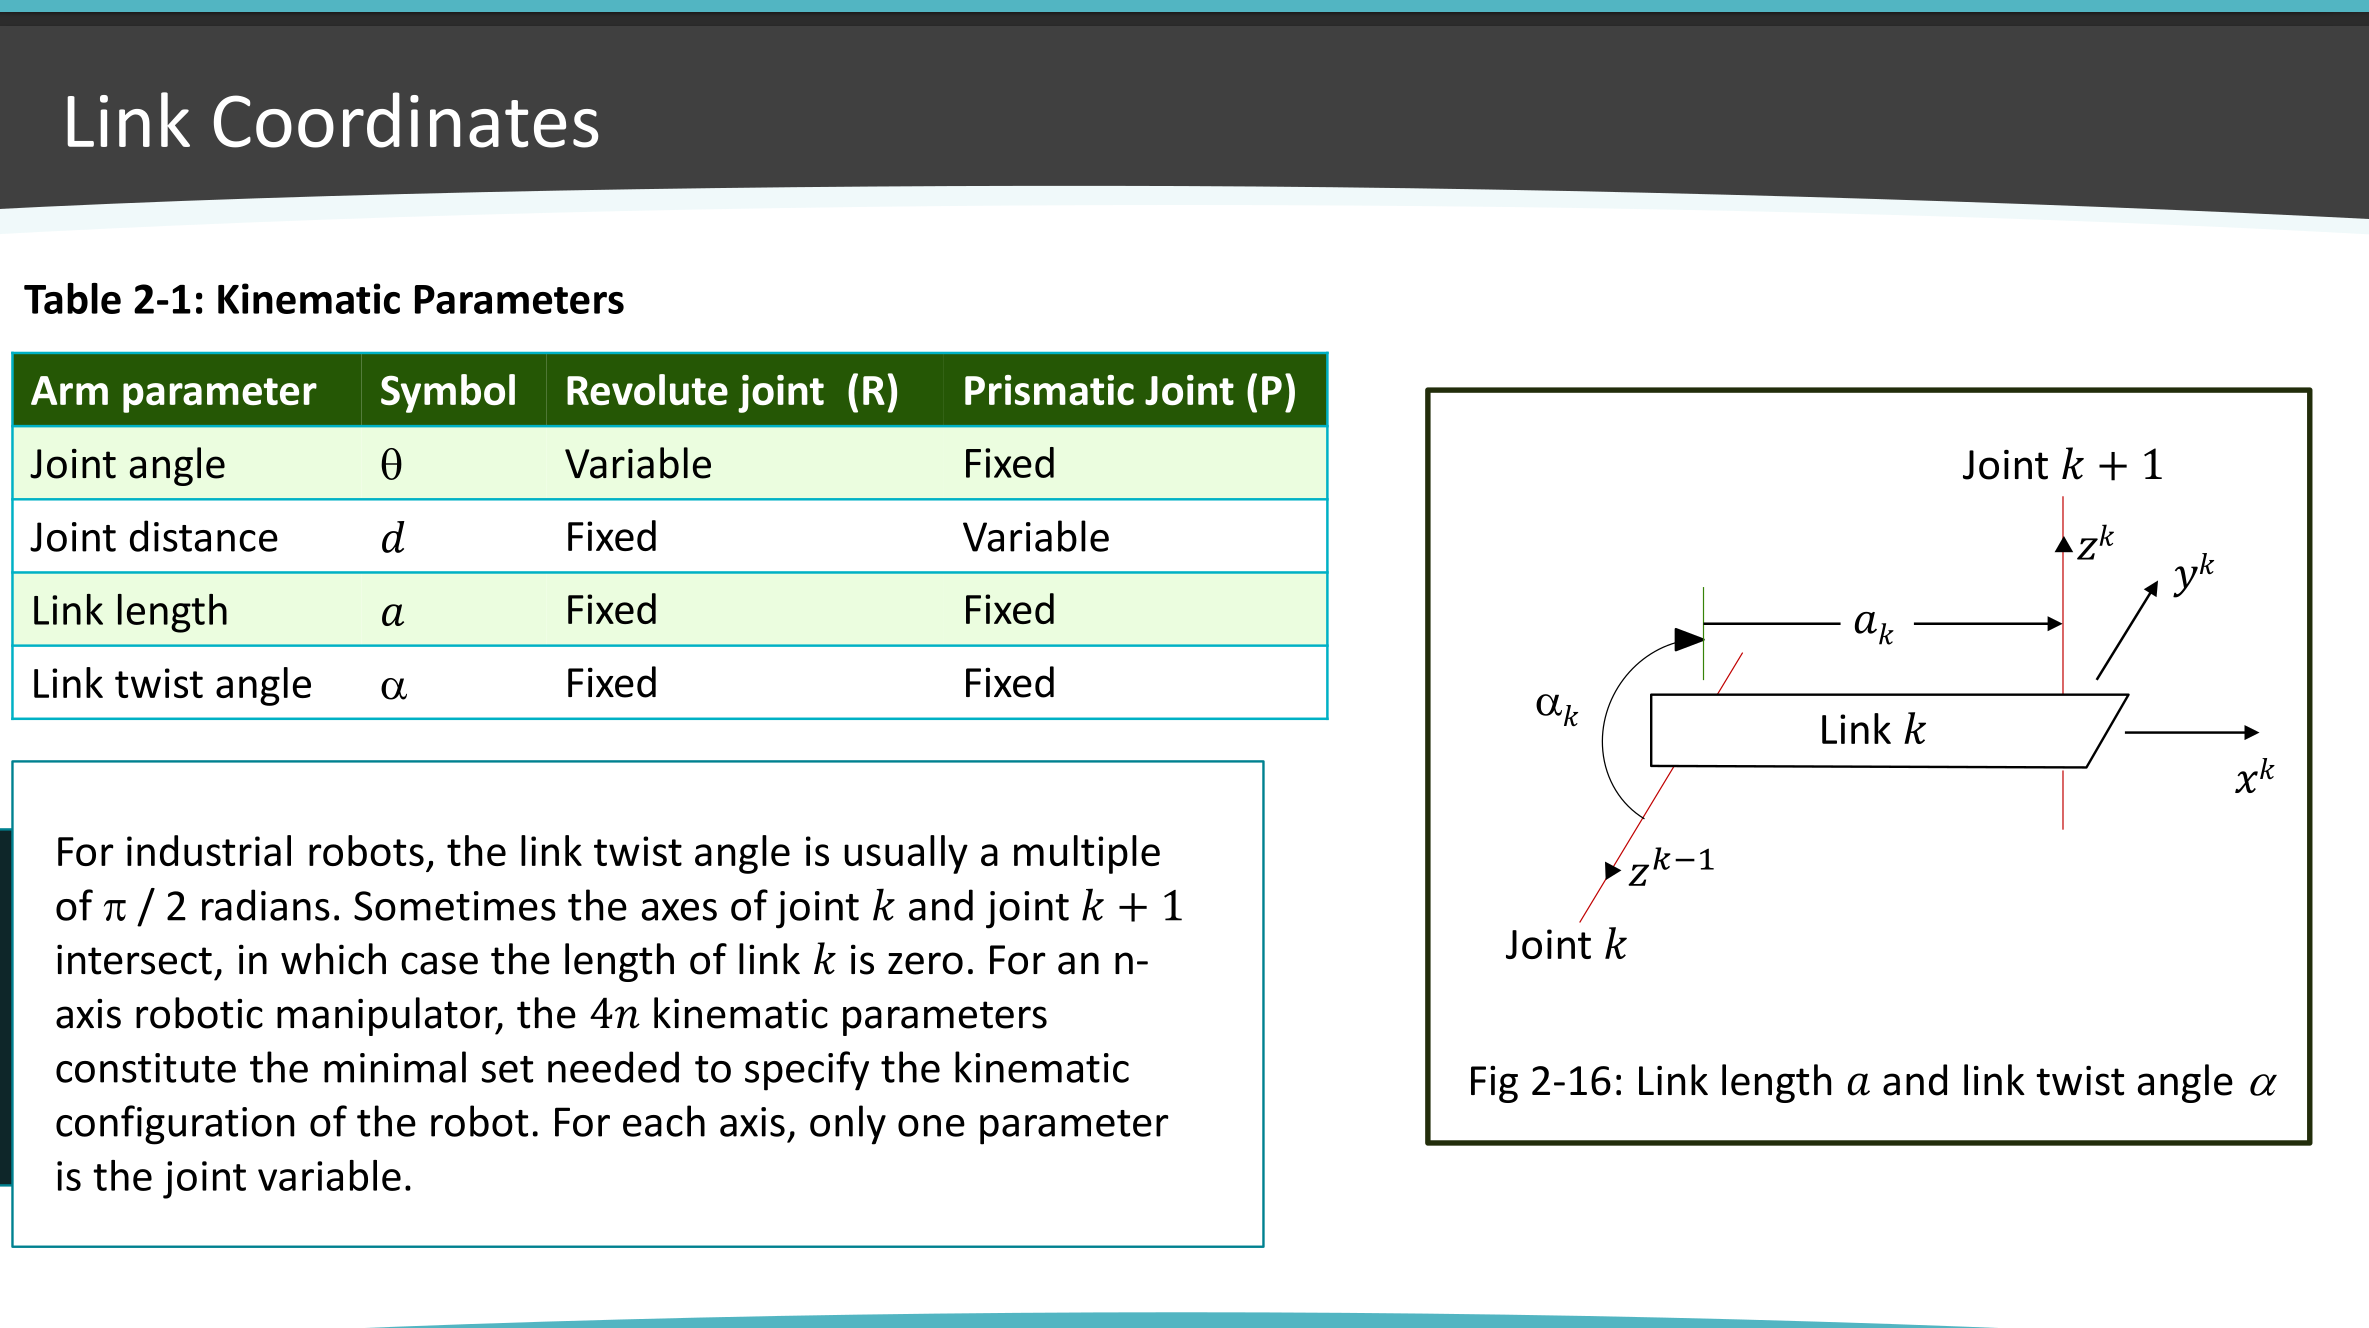
Moreover, the D-H parameters, and , behave differently when we have different types of joint. If joint is a prismatic joint, where the links and moves in the direction of , joint distance is variable and the joint angle is fixed. If the joint is revolute, then the distance is fixed since there is no straight line movement along the joint 's axis , but the joint angle is variable, since we can rotate the links and .
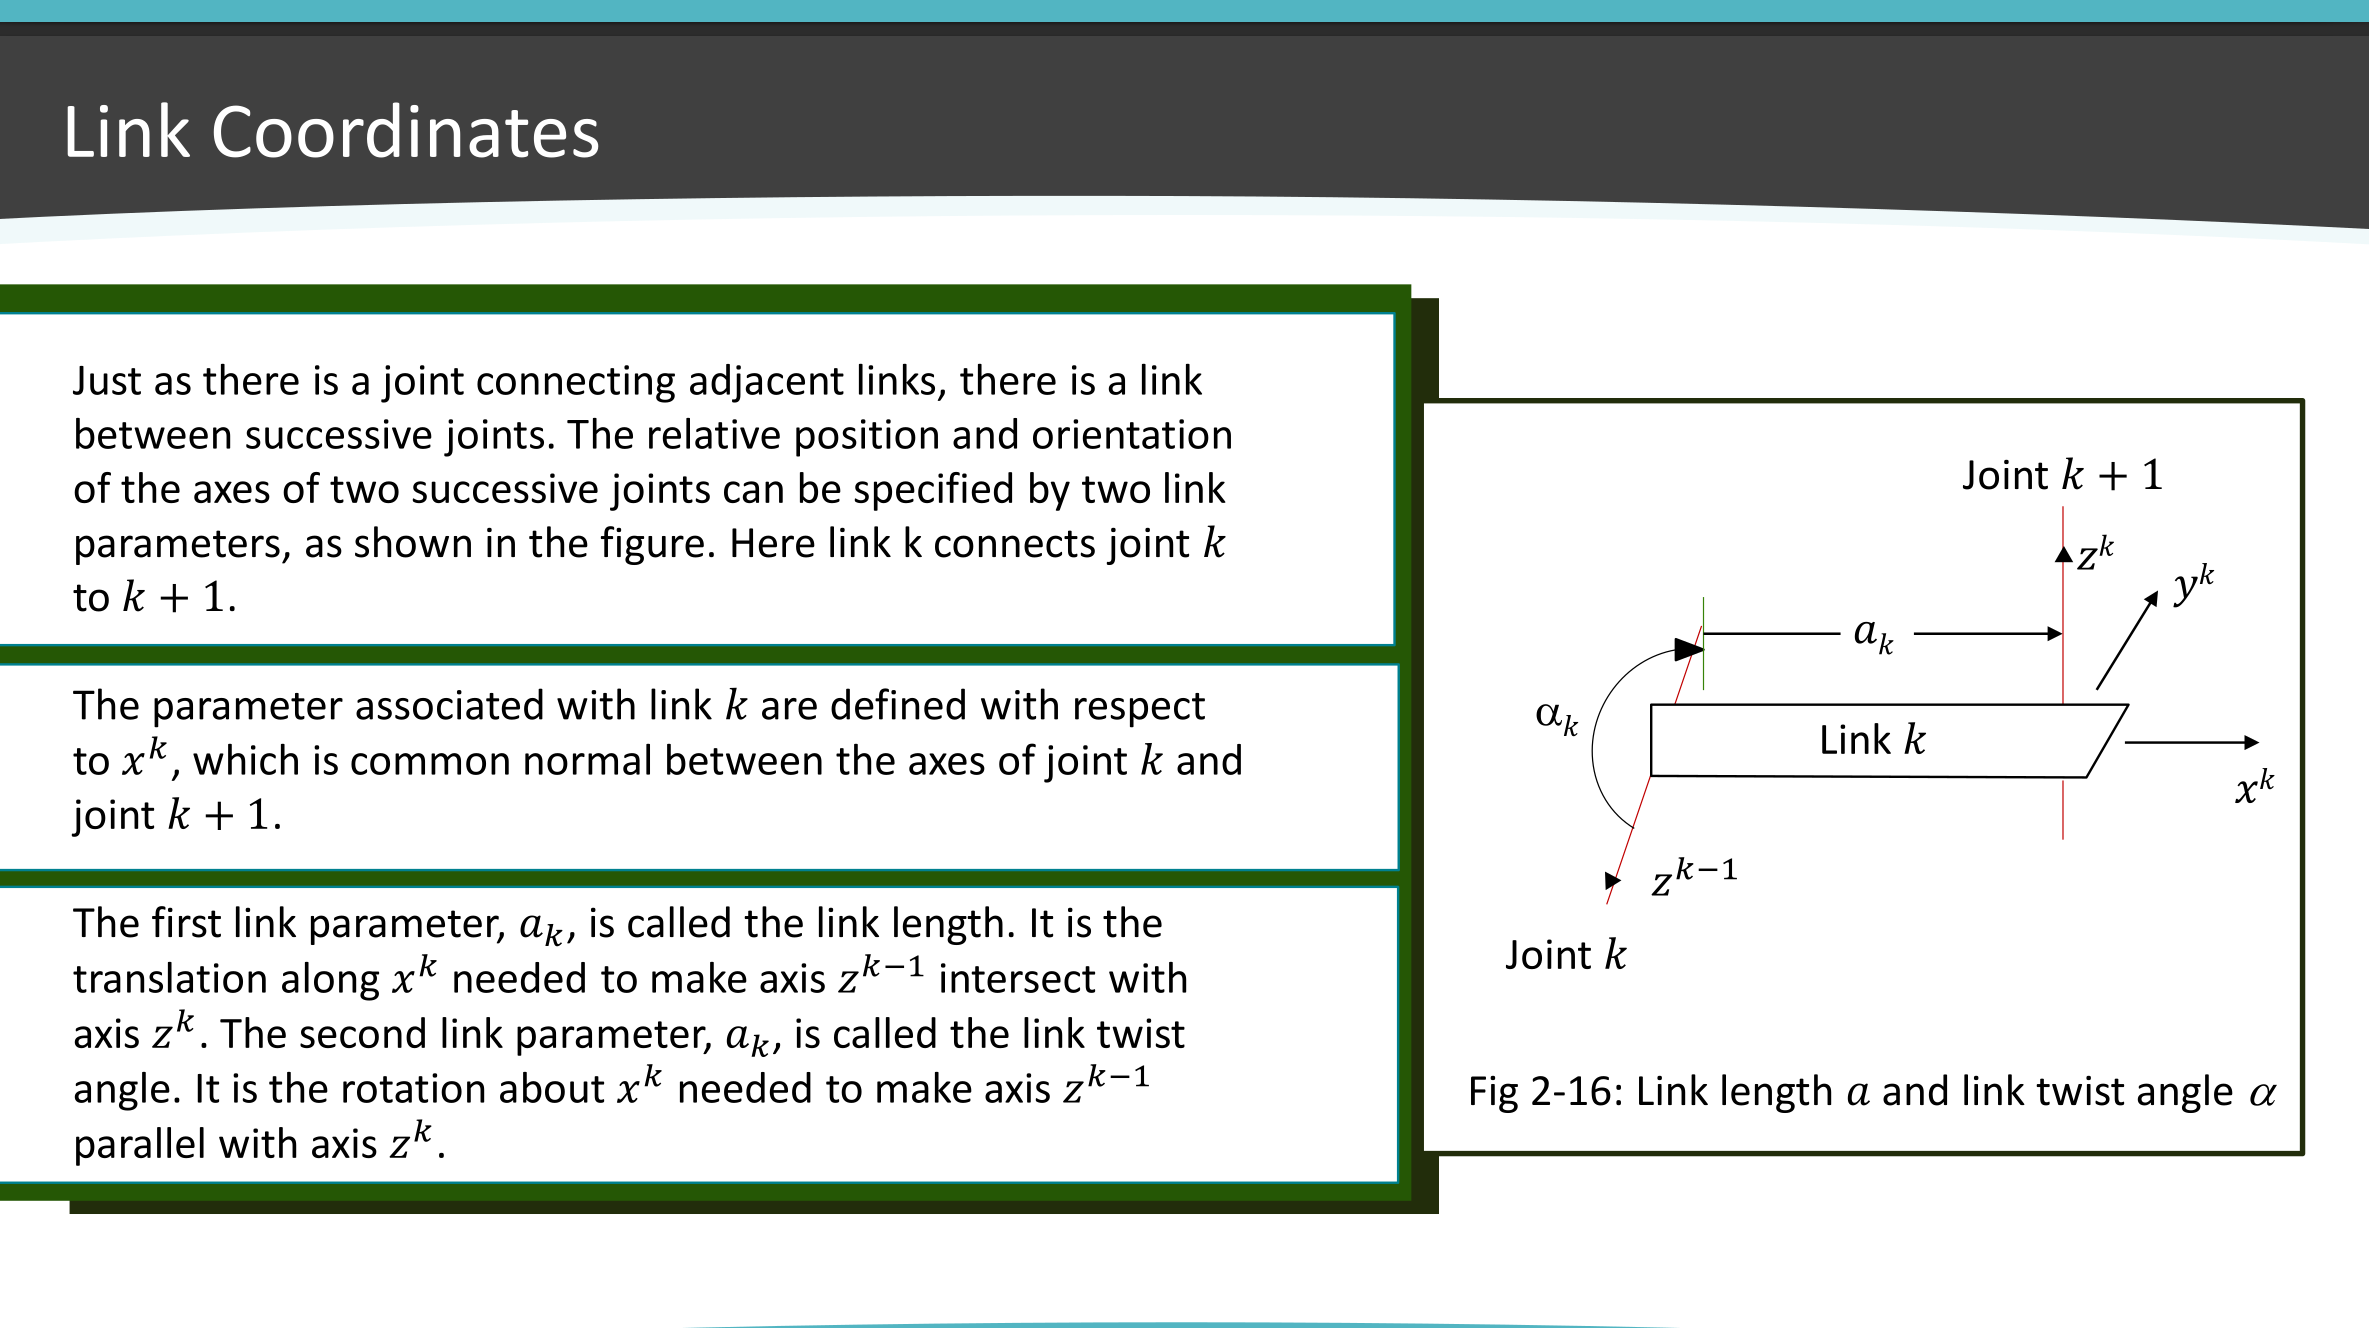
This above slide introduces another few D-H parameters, namely link twist angle, and link length, .
What the new perspective illustrates is the center link that has joints and . Joints have their and axes drawn.