Introduction
A time of flight sensor measures range from the time a pulse takes to go to an object and come back. It is one of the two principles of Range Sensing.
How it works
The sensor sends a pulse and measures the time until the echo returns. The distance and the direction of the beam together give a part of a 3D spherical shell. The object is somewhere on that shell.
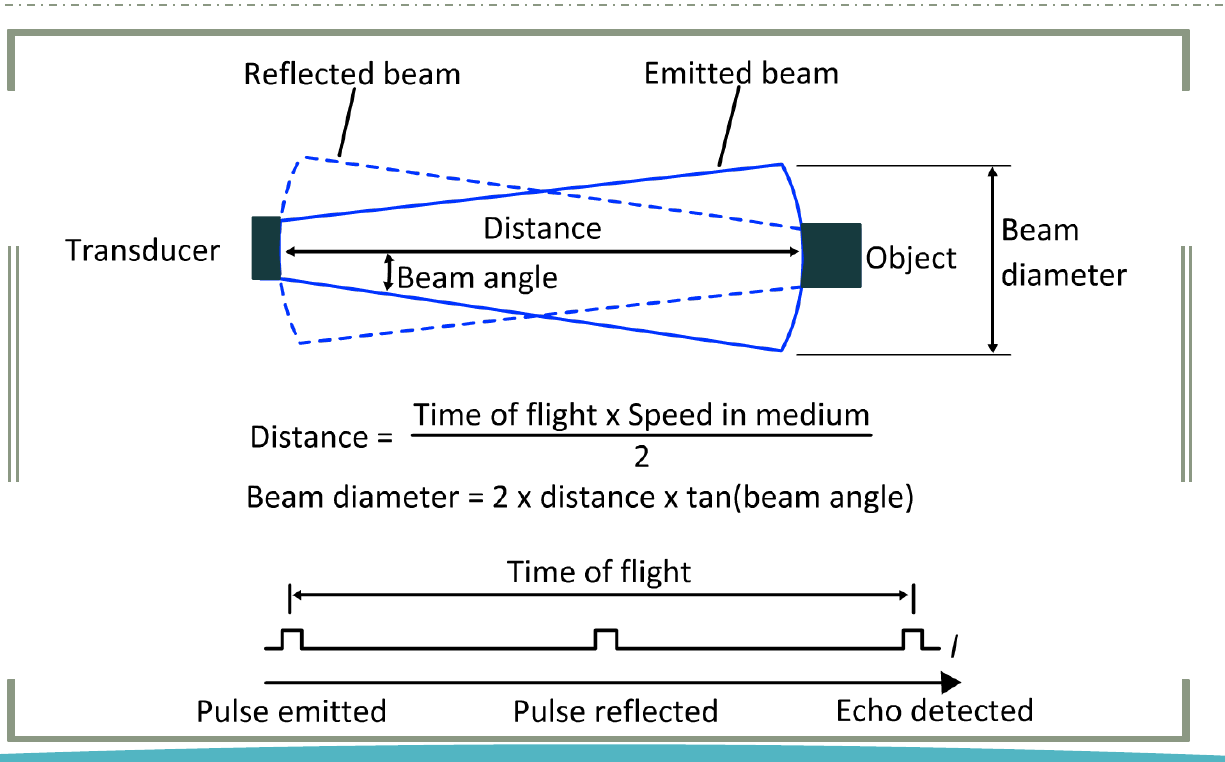
Key equations
The pulse travels to the object and back, so divide by 2:
The beam gets wider with distance: